Based on contributions by RianneDiever, alexandra.
A Doosan robot’s control box acts as a PLC: it can’t drive pneumatics directly, but it can switch a solenoid valve’s electrical signal on and off through its digital outputs, and the valve then switches the compressed air. This how-to covers wiring a solenoid valve to the robot, connecting it to a cylinder, gripper, or suction cup, and controlling it from a DRL program.
What you need
- A Doosan robot (this guide was written using an A509S)
- A compressor sized for your system (6–7 bar was used here — check your own components’ requirements)
- A solenoid valve. Which type depends on what you’re driving:
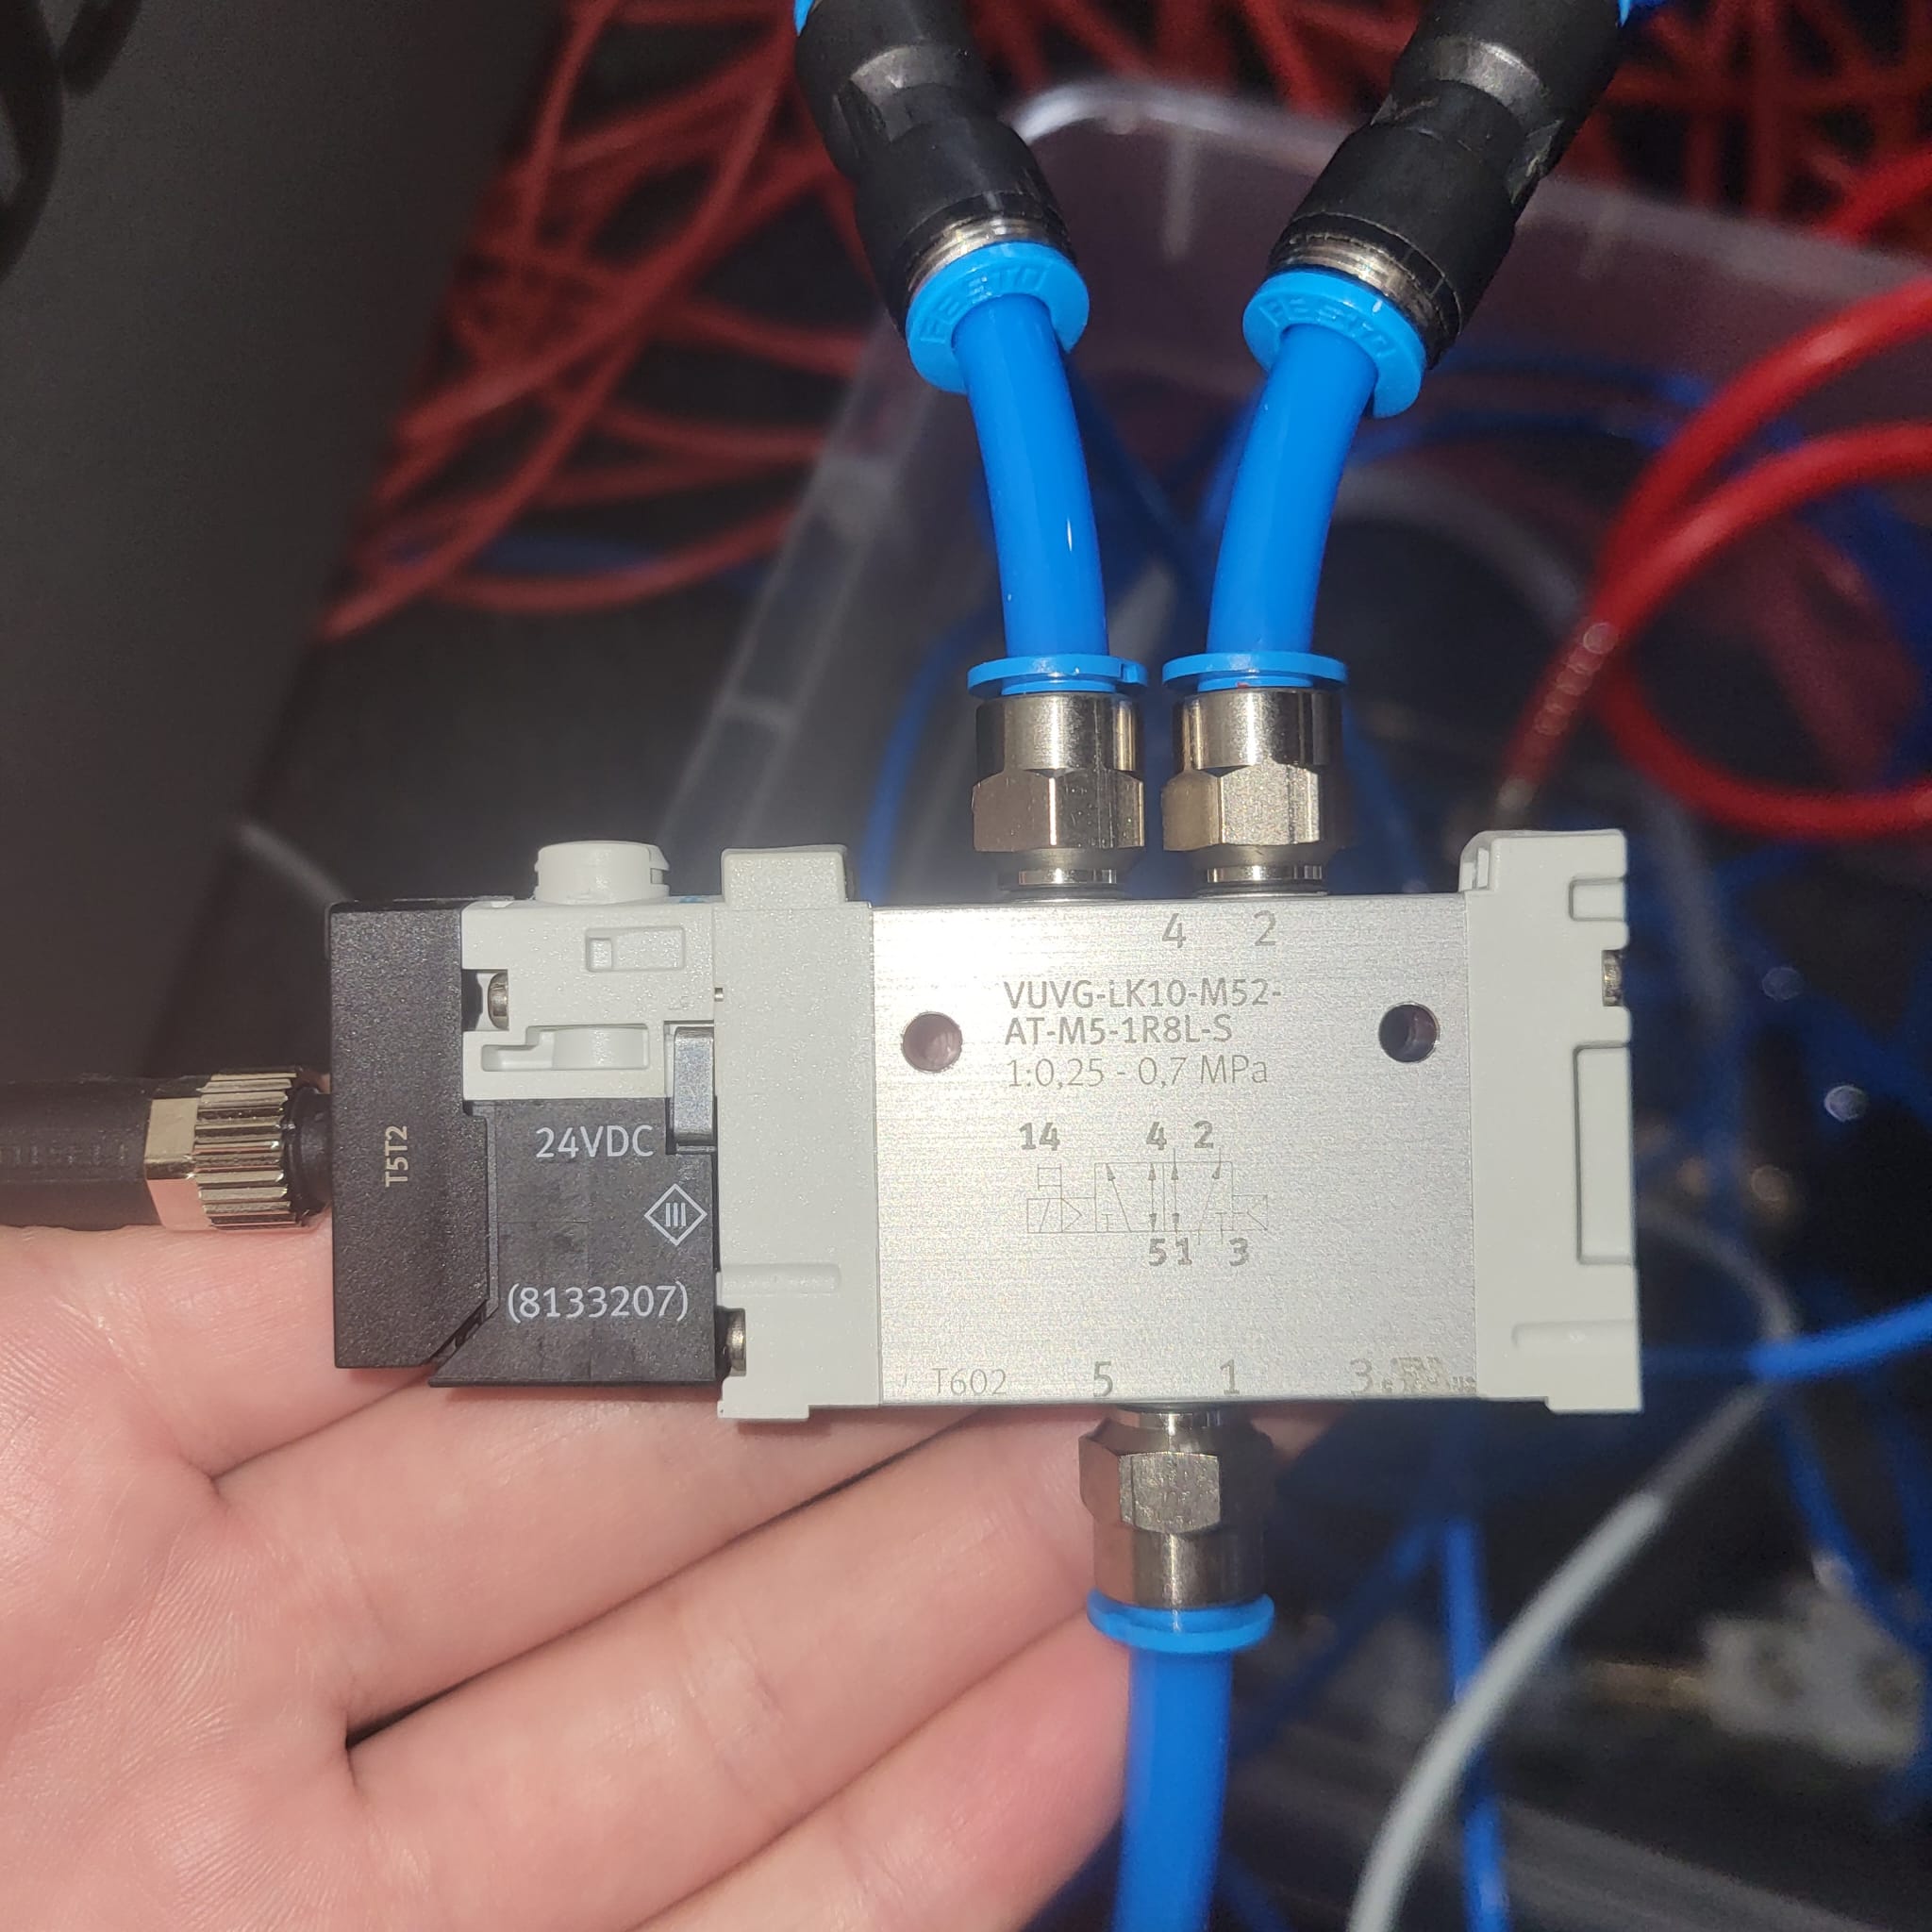
- 5/2 valve for a double-acting cylinder or gripper (e.g. Festo VUVG-LK-10-M52-1R8L-S with a Festo HGPC-20-A gripper)
- 3/2 valve to switch airflow between two paths, e.g. gripper vs. suction cup (e.g. Festo MHE3-M1H-3/2G-QS-6-K)
- A vacuum generator if you’re using a suction cup (e.g. Festo SBP HV 3 07 13 SD)
- Flow control valves (optional, to tune cylinder speed)
- A relay, if your valve’s coil draws more current than the robot’s digital output can supply directly
Warning: always power off the robot arm and release the pressure from the compressor before working on the electrical or pneumatic wiring. Working with electronics and pneumatics can be dangerous — take your time, and ask for help if you’re unsure whether something is correct. If you’re using different products than listed above, double check that the wiring details below still apply to your parts.
Steps
1. Wire the solenoid valve
Solenoid valve cables typically come in one of two forms. Which wiring approach you use also depends on the valve’s current draw.
Option A — power the valve directly from the Doosan (recommended for small valves):
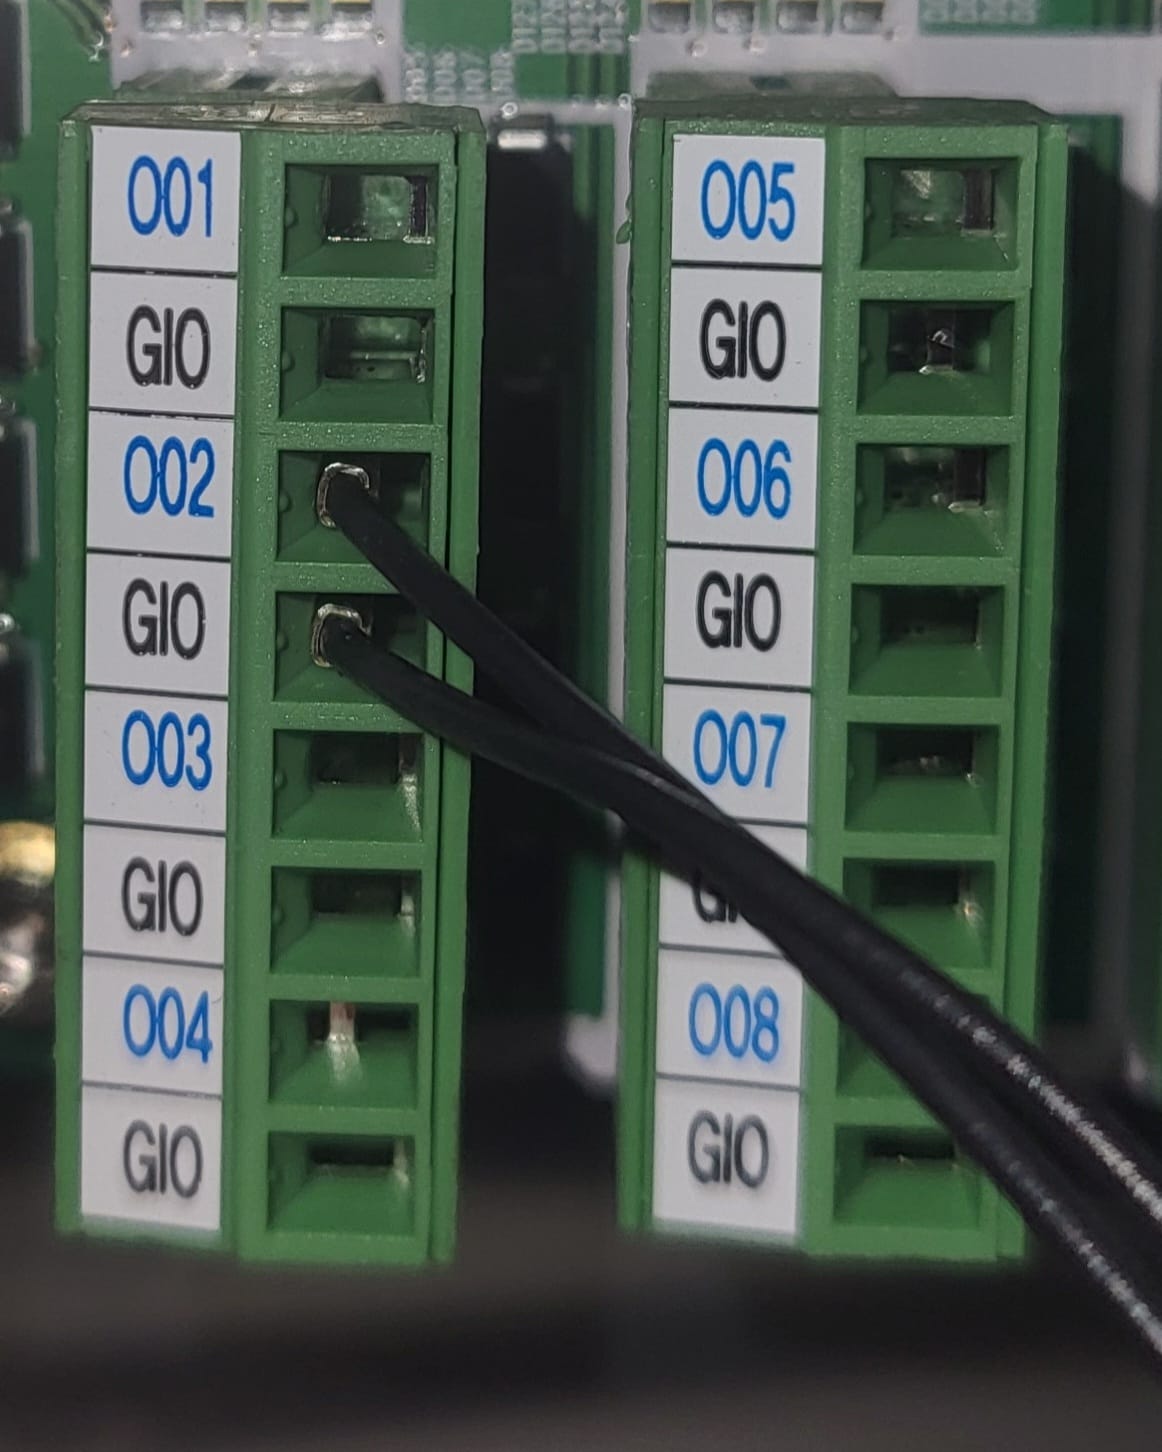
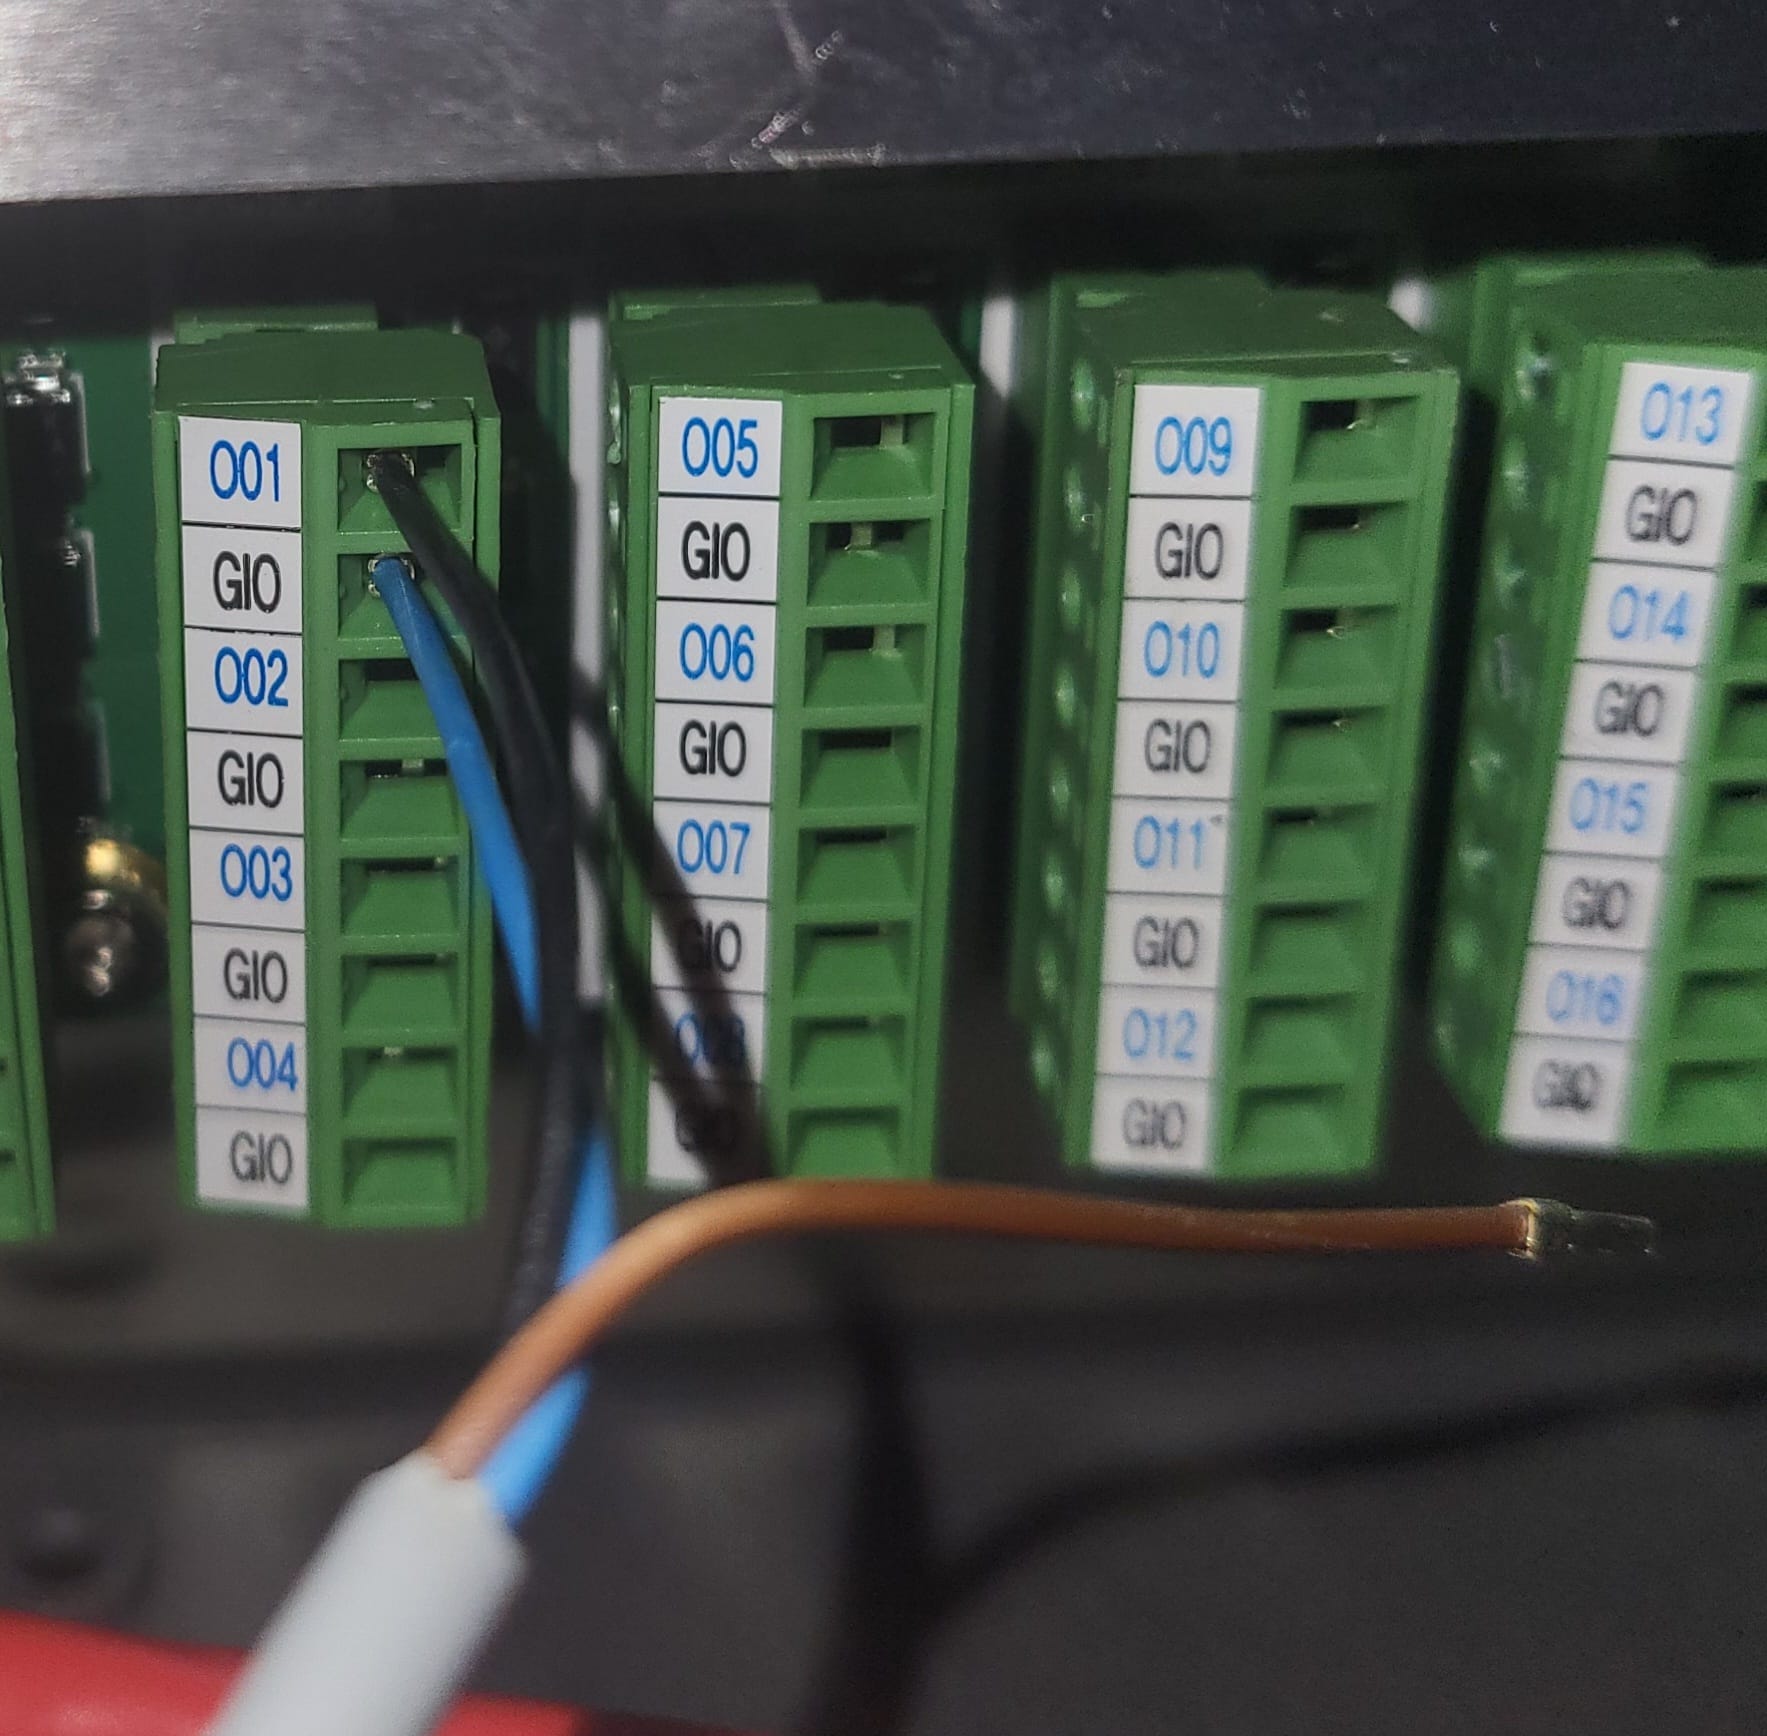
The valve works by having 24V on the circuit (on) or not (off). It doesn’t matter which order the two wires are connected in.
-
Two-wire cable (both black): connect both wires to the digital output port you want to use and its GIO pin. The digital output ports are numbered O0x (e.g. O01), with a GIO pin beneath it; the number matches the digital output number shown on the teach pendant.
-
Three-wire cable (black, brown, blue): connect the black wire to the digital output port, and the blue wire to the GIO pin. The brown wire can be left disconnected.
Option B — power the valve from an external +24V supply through a relay:
Connect the solenoid valve to a +24V power supply (this can also be the Doosan’s own supply). Route the other wire through a relay whose coil is controlled by a digital output (DO). Use this if the valve’s coil current is too high to switch directly from the robot’s digital output.
2. Test the valve before connecting pneumatics
With the compressed air still disconnected:
- Turn on the Doosan.
- Toggle the corresponding digital output on and off from the teach pendant.
- The valve should make an audible click — that confirms the electrical side works.
3. Connect the pneumatics
Cylinder (general):
- Connect the valve’s output ports to the two ends of the cylinder, one for extension and one for retraction.
- Add flow control valves on the cylinder ports if you want to tune the extend/retract speed.
- Plug compressed air into the valve’s inlet port.
Gripper, using a 5/2 valve:
-
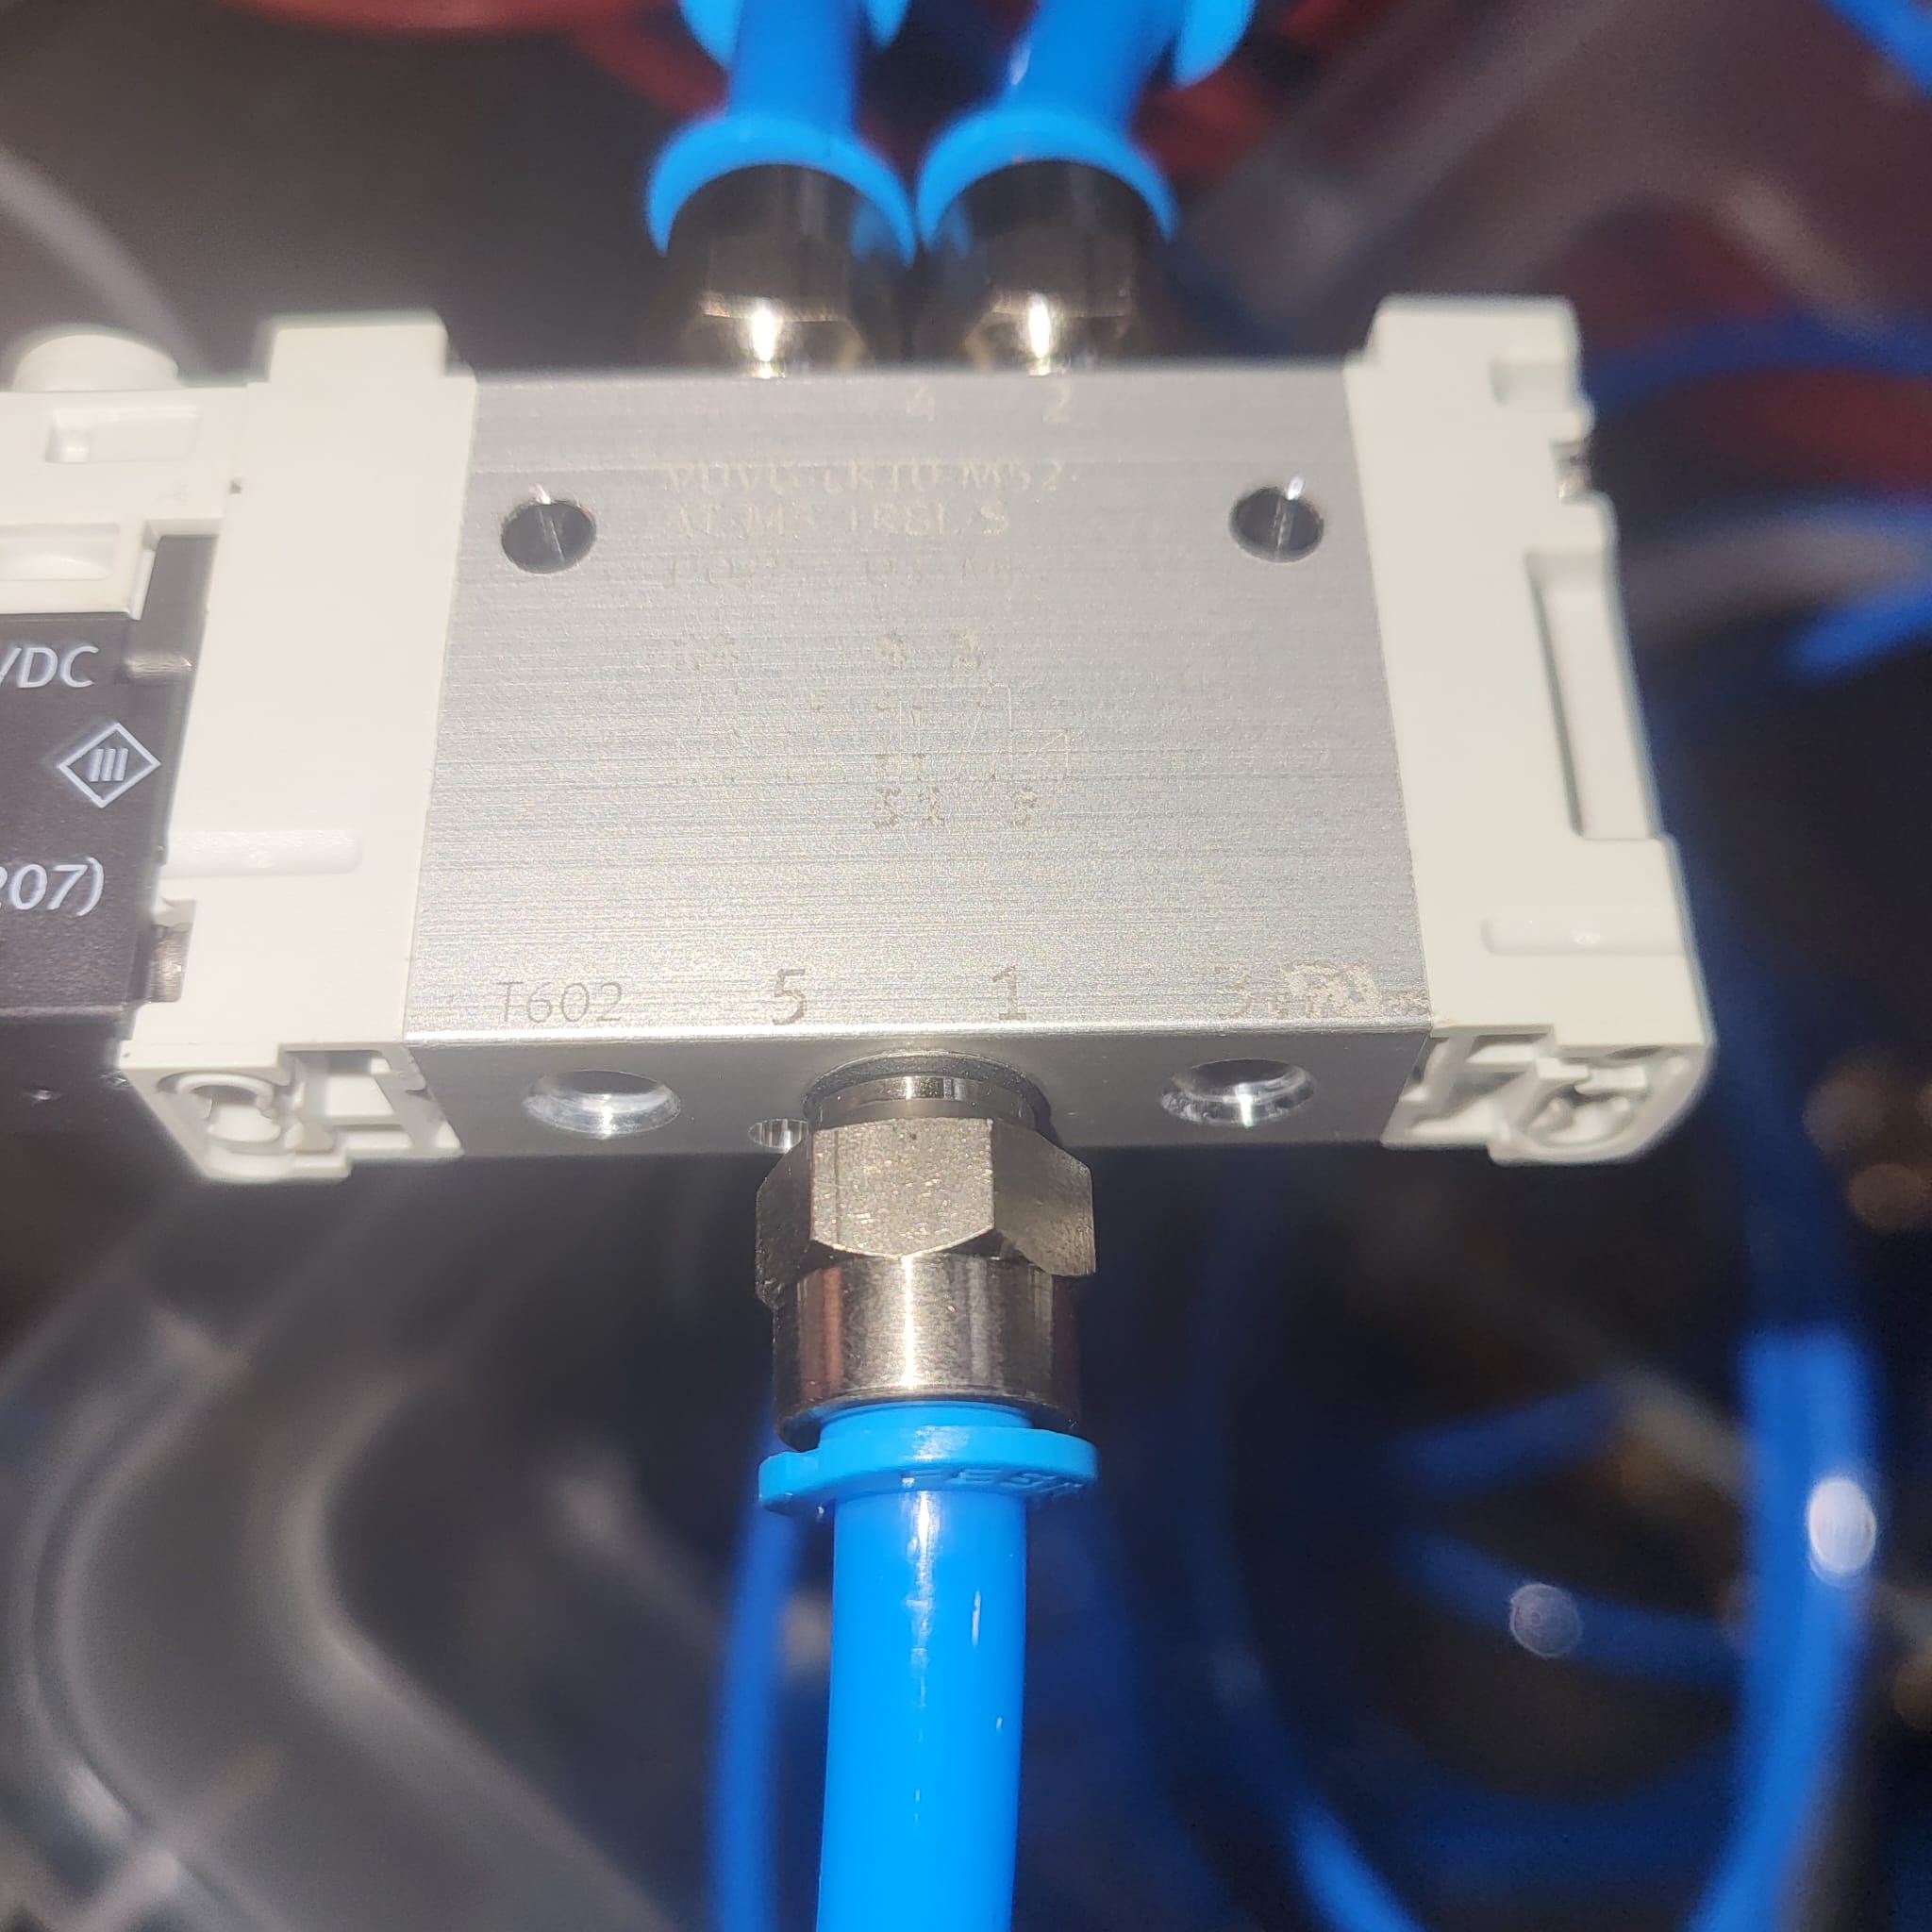
Connect compressed air to the valve’s inlet.
-
Connect the valve’s two outlets to the gripper’s inlet/outlet ports.
Suction cup, using a 3/2 valve and a vacuum generator:
-
Connect compressed air to the inlet of the 3/2 valve. Depending on whether the valve is on or off, air flows out through outlet 1/33 or 3/11.
-
Connect one outlet to the gripper, and route the other through a vacuum generator to the suction cup. The vacuum generator converts the compressed-air flow into a vacuum.
Switching a single 3/2 valve between gripper and suction cup means only one of them can be used at a time. If you need both simultaneously, you’ll need a different valve arrangement (e.g. one valve per end-effector) — not covered here.
-
If you’re also using components that need a lot of airflow (like suction cups), connect them to the compressed-air distribution block first, so they get priority on the available air. Also check that your compressor’s capacity matches what all your components together require.
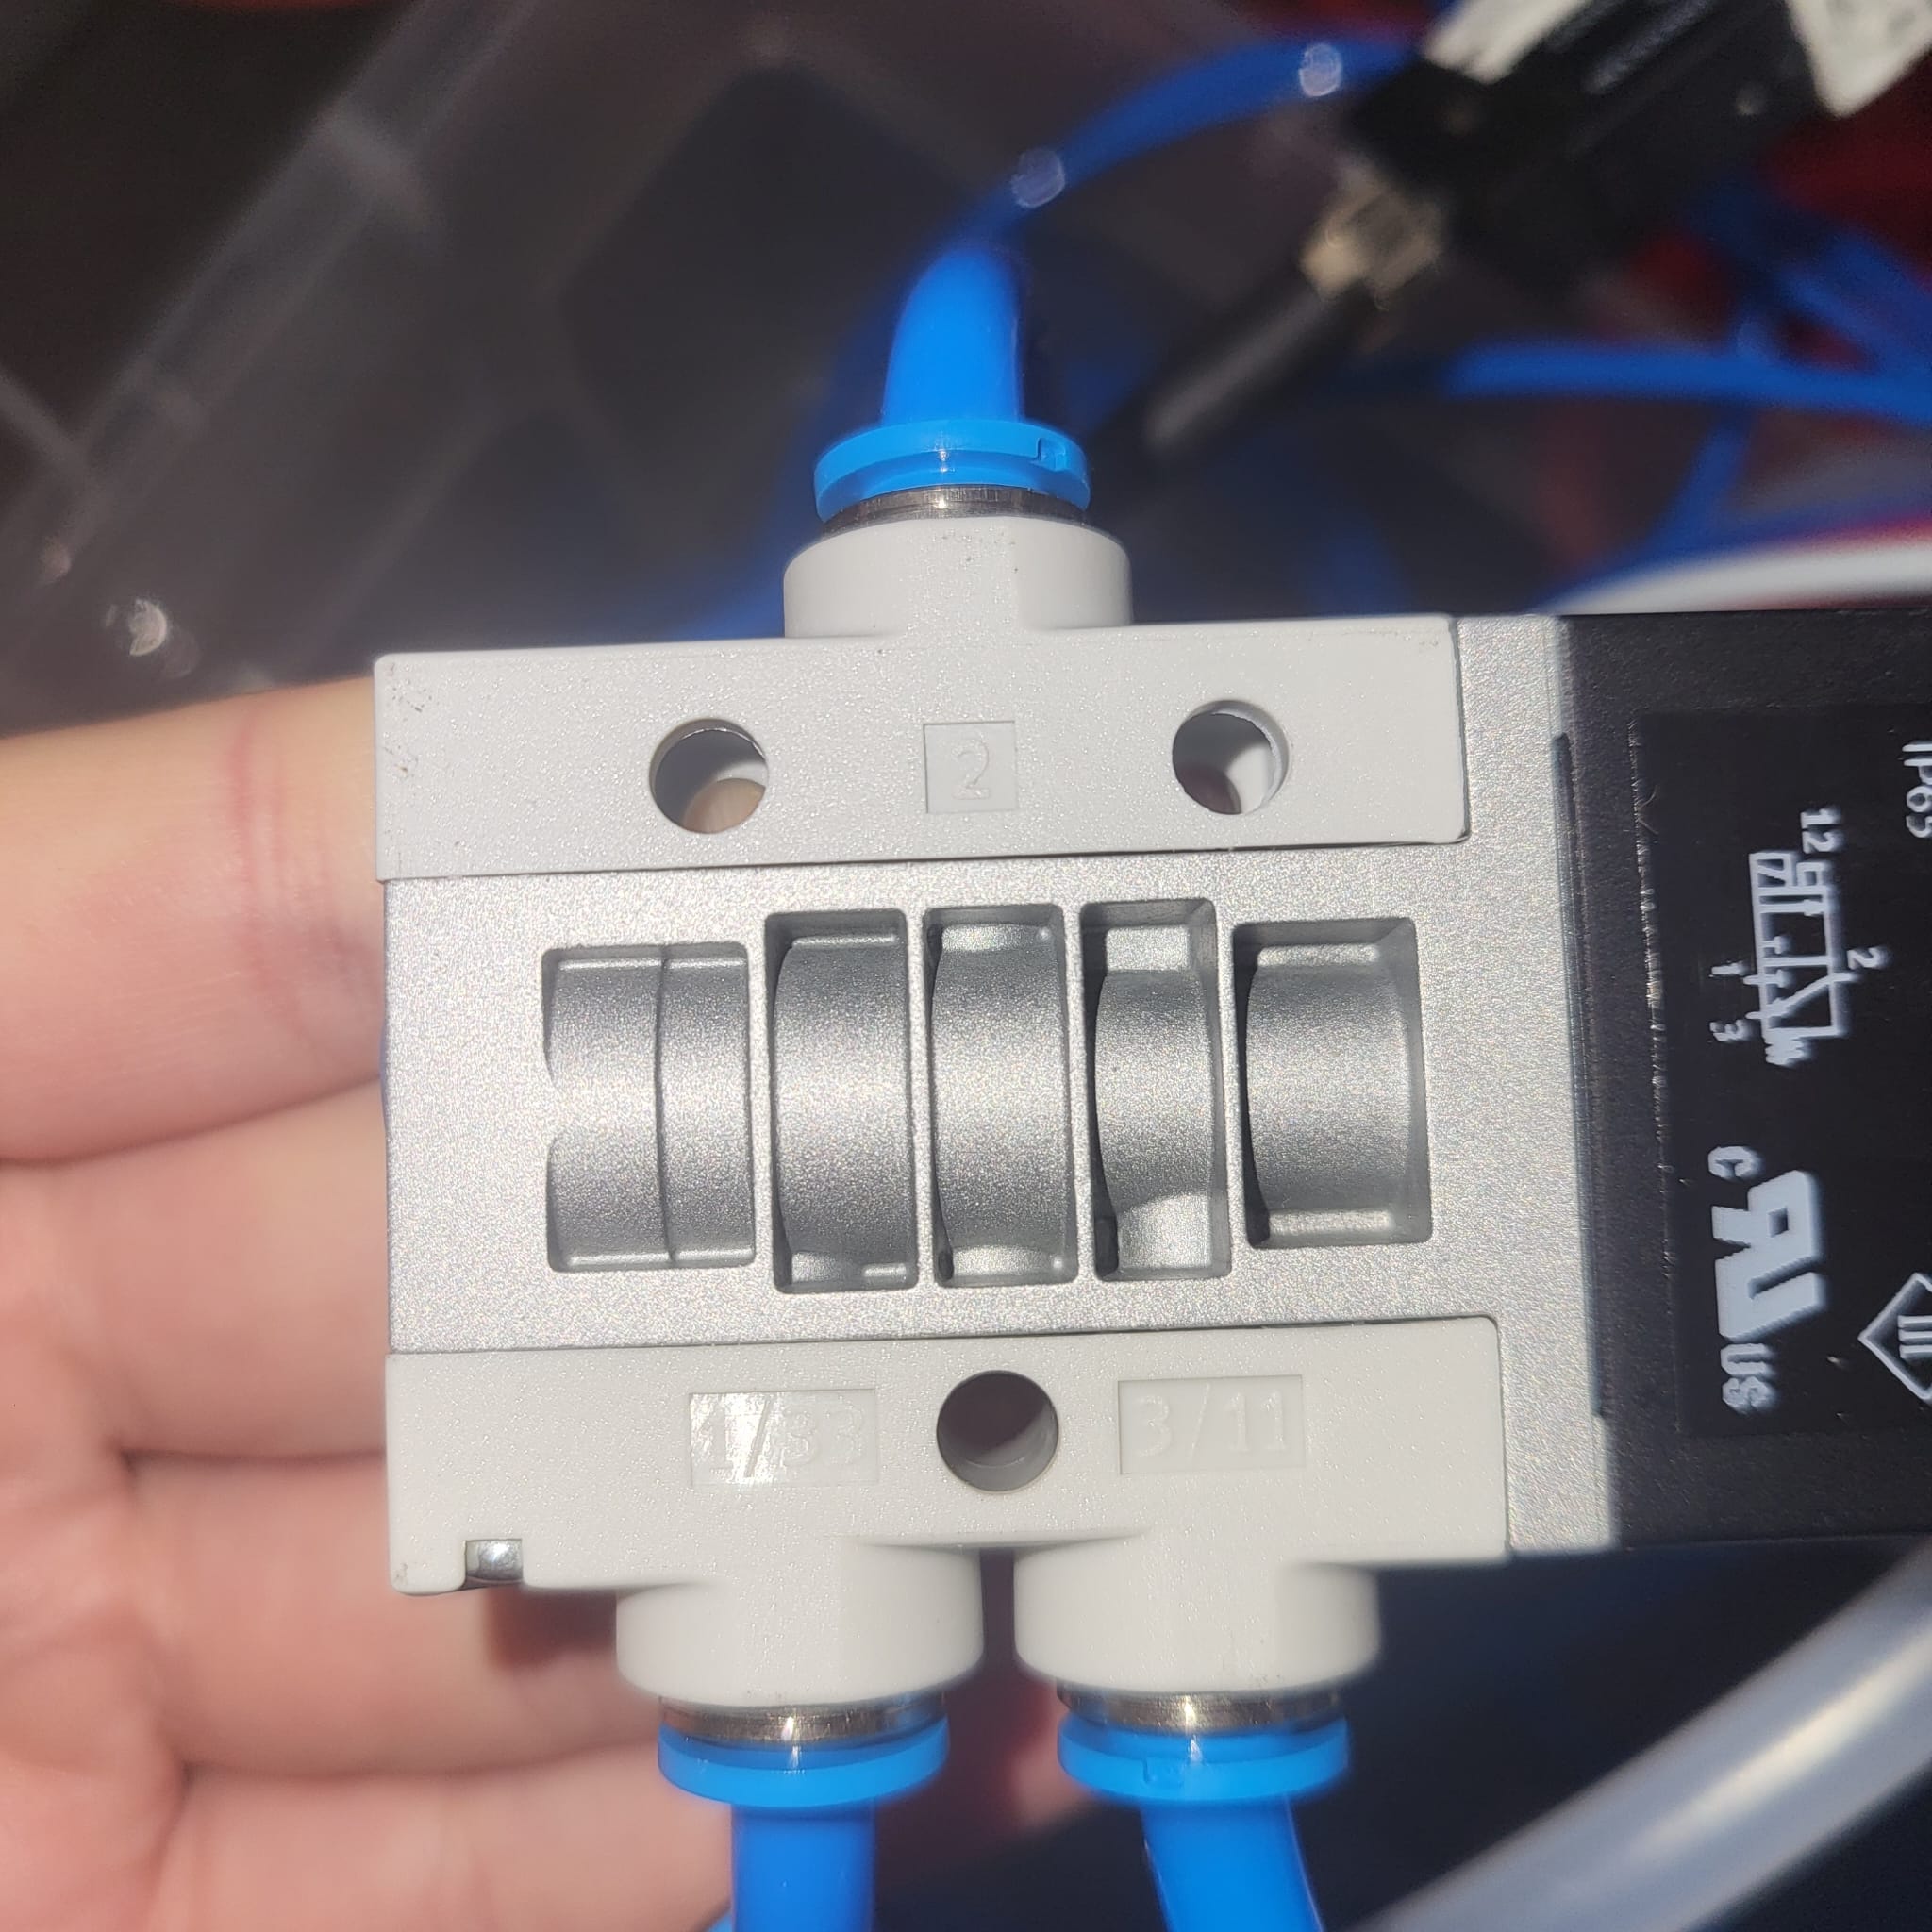
4. Program the digital output
Once wired, you can toggle the valve from the teach pendant, or from a DRL program:
# extend / activate
set_digital_output(1, ON)  # replace 1 with the O0x number where the valve is connected
wait(0.8)                  # wait for the cylinder/actuator to fully extend

# retract / deactivate
set_digital_output(1, OFF)
wait(0.8)
Safety
- Always power off the robot and release pressure from the compressor before working on the electrical or pneumatic system.
- Enclose your pneumatic system where possible.
- Use emergency stops and label your pneumatic wiring clearly.
- Design safety in from the start rather than adding it as a last-minute change.
- When adjusting the system later, disconnect the air supply from the valve first.
Troubleshooting
- Valve doesn’t click when toggled from the pendant: re-check the digital output number matches the O0x number wired, and confirm the GIO/return wire is connected.
- Cylinder moves too fast or slams: add flow control valves on the cylinder ports and tune them.
- Not enough air pressure at the suction cup or gripper: check the compressor’s capacity against everything connected, and make sure high-flow components are connected to the distribution block first.
Related
- How to use the analog I/O ports on a Doosan robot
- How to connect a Doosan digital I/O port to a microcontroller using a transistor
Rewritten and consolidated (Sept 2026) from the original student how-to’s: How to Connect a Valve to a Doosan (Gripper / Suction cup), How to connect pneumatic system to Doosan.