Based on contributions by A.Vonk.
KIDE’s Interface Panel editor lets you add custom buttons and displays to the Kawasaki teach pendant, wired to internal signals you can read from your AS program. This is useful for simple on-pendant controls like a start button.
What you need
- A Kawasaki robot controller with KIDE software access to the Interface Panel editor
Steps
1. Open the Interface Panel editor
Go to the interface panel tab in KIDE.
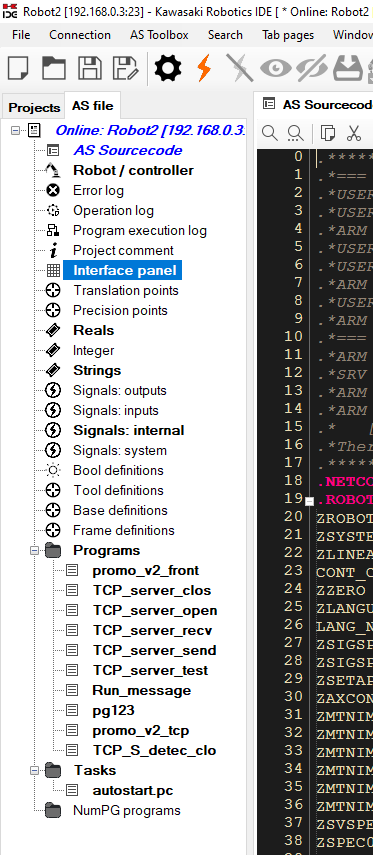
2. Add a panel
Select a panel to edit, and double-click it to add a panel type.
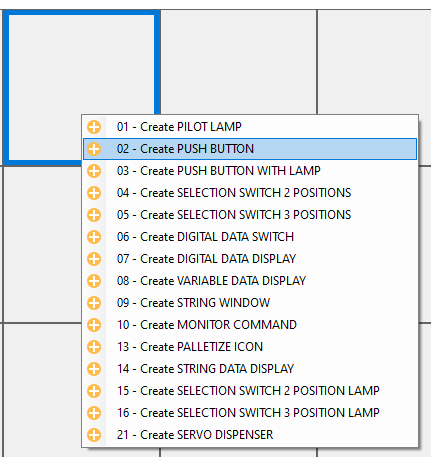
3. Configure the panel
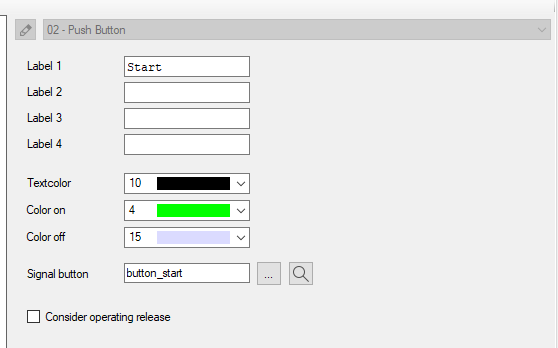
Configure the panel’s labels and colors. This example creates a start button:
- Label 1–4: the four lines of text shown on the button
- Texcolor: the text color
- Color on: the button’s color while pressed
- Color off: the button’s color while released
- Signal button: the internal signal that reports the button’s state (assigned in the next step) — this is the most important setting
4. Assign a signal number
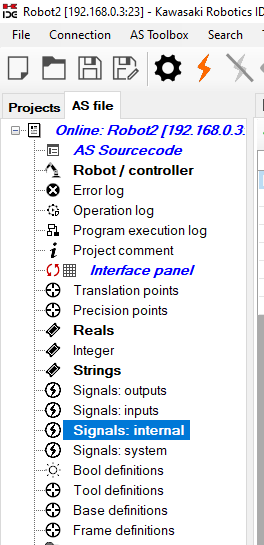
In the Signals section, add a new internal signal and give it a number. Numbers below 2130 are reserved or already used by the controller — use a number between 2130 and 2999. Never reuse the same number for two signals: a signal number is a memory address, and reusing one causes unpredictable behavior.
5. Read the button from your AS program
WHILE TRUE THEN
  IF SIG(button_start) == TRUE THEN
    PRINT "Value True"
  ELSE
    PRINT "Value FALSE"
  END
END
This loops forever, printing the button’s current state. Replace button_start with the signal number/name you assigned in step 4, and replace the PRINT calls with your own logic.
Common mistakes
- Using a signal number below 2130 — these are reserved or already used by the controller and can cause unpredictable behavior.
- Reusing the same signal number for two different buttons or signals.
Related
- How to control a Kawasaki robot with the PromoBot Python class
- How to pause a Kawasaki robot on command using a background PC program
Rewritten and consolidated (Sept 2026) from the original student how-to’s: How to create custom GUI on Kawasaki robot Teach pendent.