Based on contributions by Jasonbrowne.
Standard SolidWorks mates make an assembly fully static. Mechanical mates instead give you a dynamic assembly where parts can move within limits you define — useful for checking a design’s range of motion before you build anything.
What you need
- SolidWorks.
- An assembly with parts you want to move relative to each other (e.g. a cobot base and its first link).
Use cases
- Modelling the movement (and restrictions) of a cobot.
- Trying out different layouts in an assembly line.
- Testing standard mechanisms and constraints like a hinge, gear, rack-and-pinion, or universal joint.
Steps
The example below uses the hinge mate on the base of a UR5e cobot.
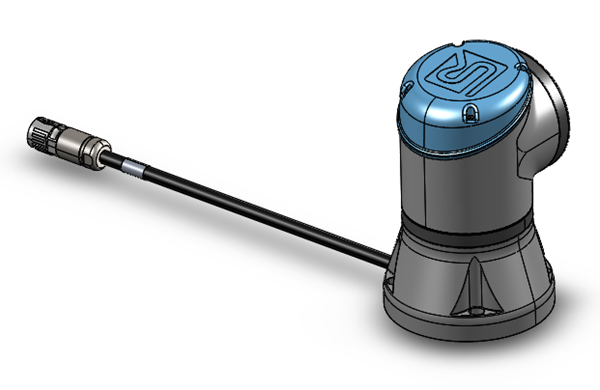
1. Open the mechanical mate
The base connection here consists of the mounted base and link 1. Go to the Mechanical tab of the Mate dialog.
A hinge mate needs three things: concentric selections, coincident selections, and (optionally) angle limits.
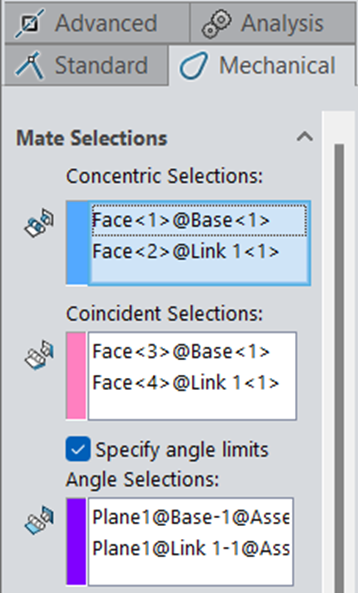
2. Add the concentric selections
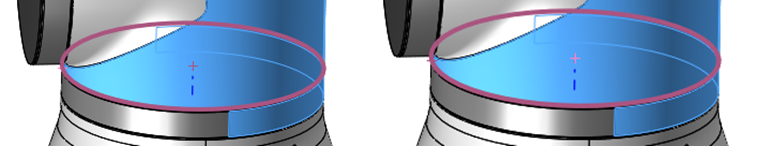
Select the round shapes that form the hinge axis — here, the housing of link 1 and the corresponding round feature on the end of the base.
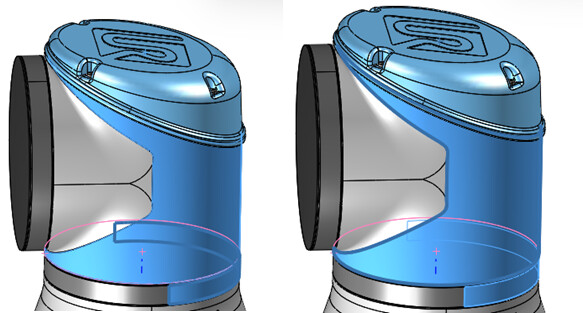
3. Add the coincident selections
Select the surfaces or edges that should stay flush — here, the top surface/edge of the base and the bottom surface/edge of link 1.
4. Specify angle limits (optional)
If you don’t want the parts to rotate freely, add angle limits to constrain the movement.
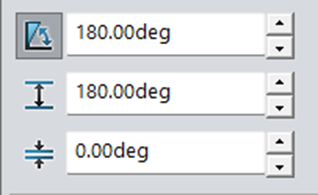
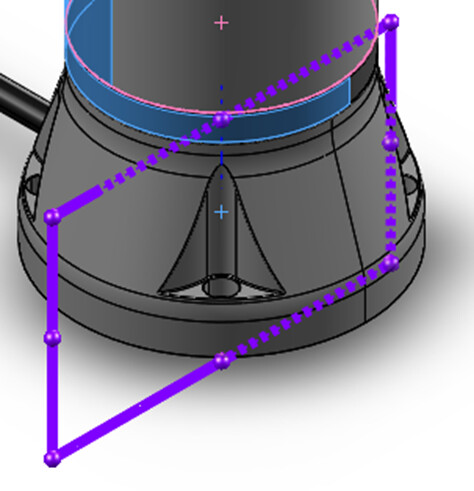
For a part like the cobot base that has no flat surfaces to reference directly, add reference planes to the individual parts (not the assembly) and link those planes to each other for the angle limit. The alignment isn’t always obvious from the plane names alone, so try different combinations and check the result visually.
5. Repeat for every joint
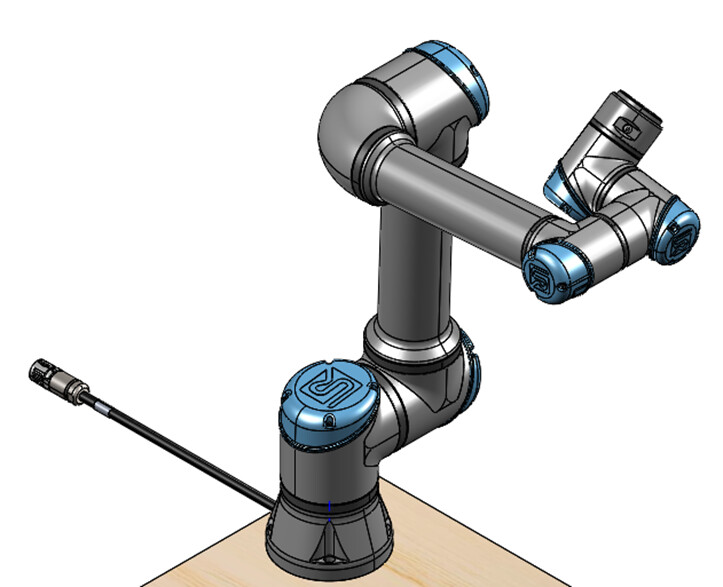
Repeat the process for each link in the chain. The result is a realistic assembly of the cobot (or any linked mechanism) that moves correctly within its defined limitations.
Troubleshooting
- Hinge rotates the wrong way or flips unexpectedly — the reference plane alignment used for the angle limit isn’t always intuitive; try the alternate plane pairing and re-check visually.
- Parts don’t move at all — check that no leftover standard mate (e.g. a rigid mate between the same two faces) is still constraining the joint.
Related
Rewritten and consolidated (Sept 2026) from the original student how-to’s: How to use Mechanical Mates (Hinge).