Based on contributions by LuisdeSantiago.
By default a Doosan robot expects to be mounted on a table, base down. If you mount it on a wall or the ceiling instead, you must tell the controller the robot’s new orientation in its world coordinates, otherwise gravity compensation and safety limits will be calculated for the wrong pose.
What you need
- A Doosan robot (e.g. M1013) physically installed on the wall or ceiling
- Access to the teach pendant
- The exact mounting height and orientation of your installation
Steps
1. Unpack the robot
Go to the “Status” screen and press the recovery button.
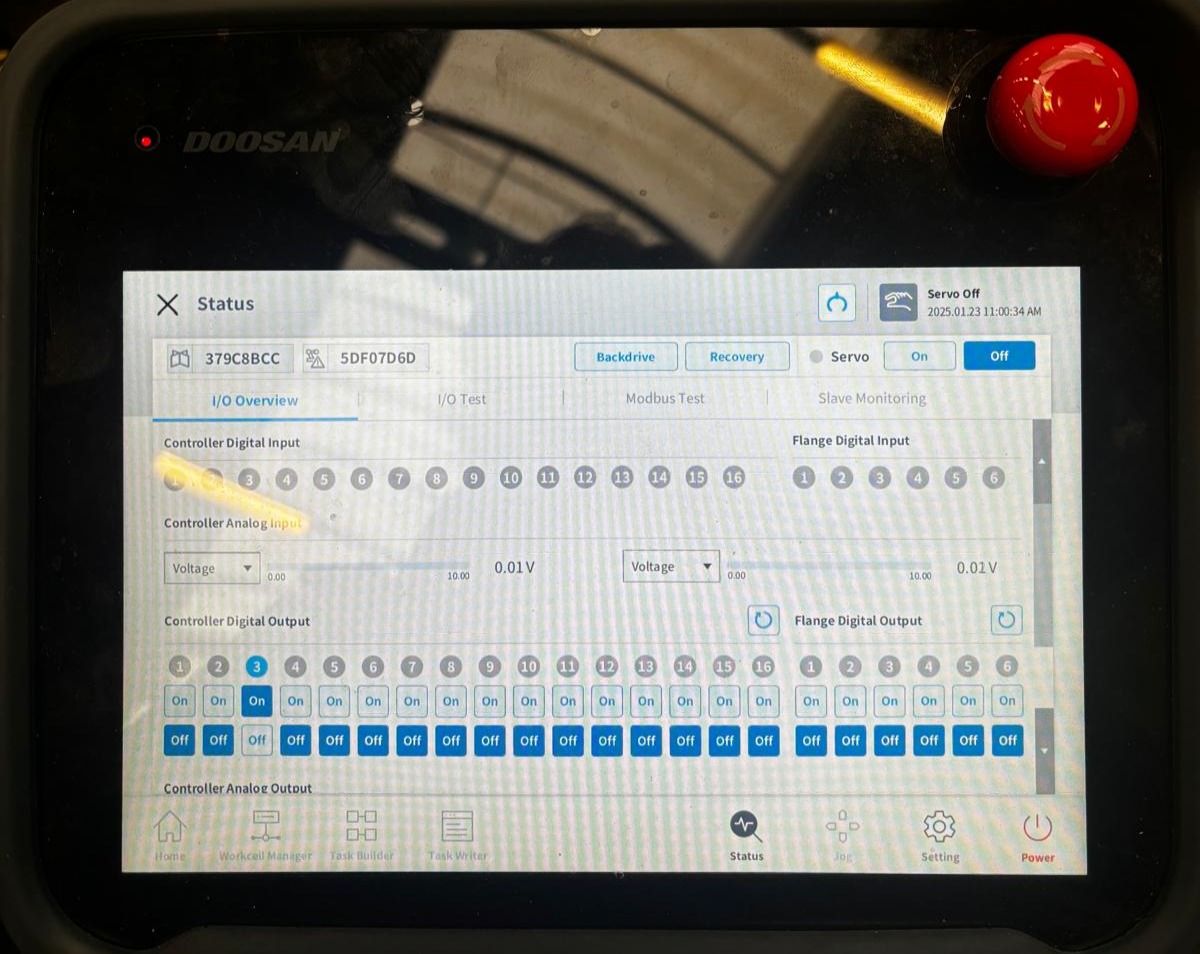
2. Confirm the unpack
Press and hold the unpack button until the robot stops moving. The robot is now fully unpacked.
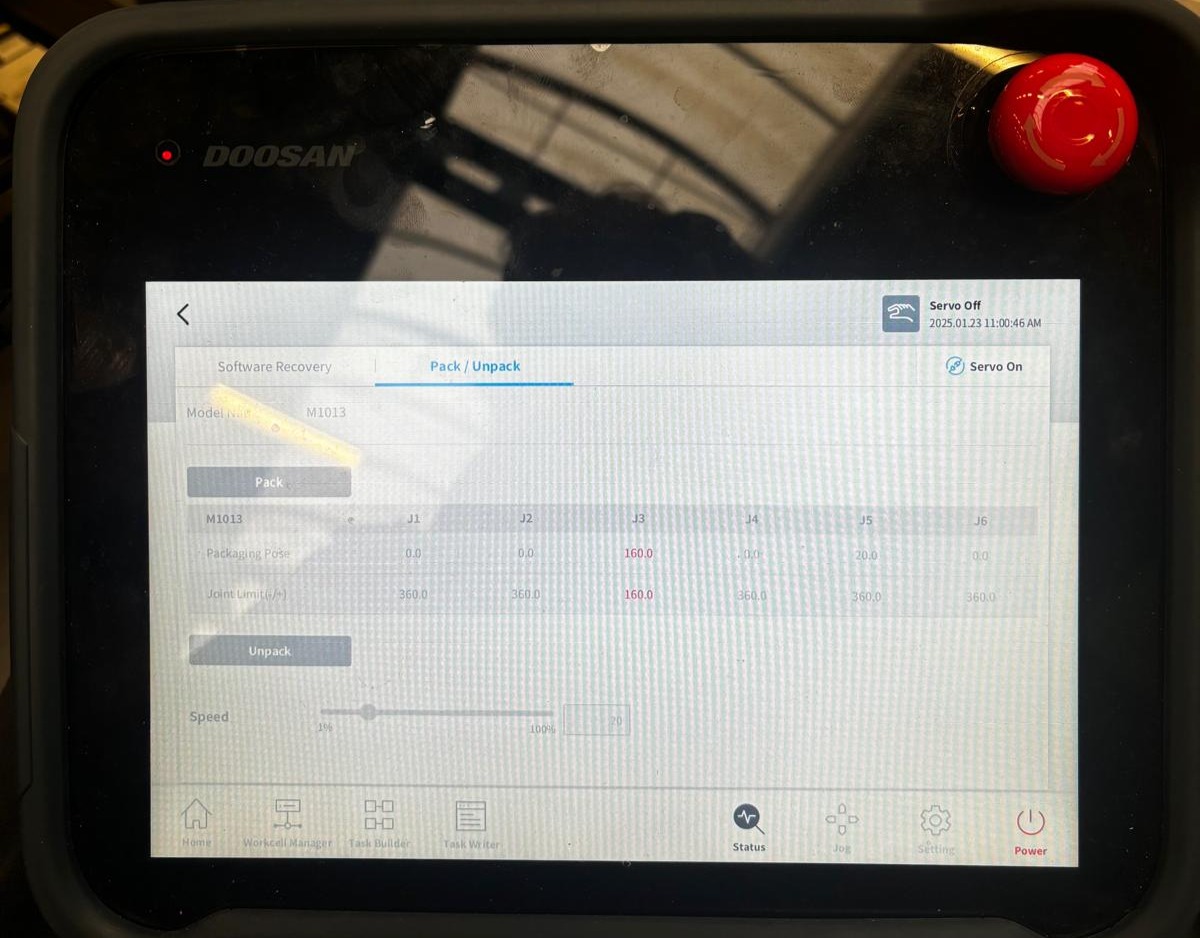
3. Open the Workcell screen
Go to the “Workcell” screen.

4. Set the world coordinates
Find “World coordinates” and enter the values that match your installation. For a robot mounted upside down on the ceiling, 2 m above the ground, the values used were:
| Axis | Value |
|---|---|
| X | 0.0 mm |
| Y | 0.0 mm |
| Z | 2000.0 mm (mounting height above the ground) |
| A | 0.0° |
| B | 180.0° |
| C | 180.0° |
Check: the source listed the last row as “Z: 180.0” instead of “C: 180.0”. World coordinates only have one Z (position) value; the three rotation values are A, B and C. This has been corrected to C above, but double-check the exact rotation values for your own mounting orientation on the pendant — don’t copy these numbers blindly, they depend on how your robot is physically oriented.
Once the world coordinates match your mounting, the robot is ready to use.
Related
Rewritten and consolidated (Sept 2026) from the original student how-to’s: How to set up a Doosan M1013 on the ceiling/wall.