Based on contributions by Erik_Endlich.
Space limits restrict where the robot (or its tool) is allowed to move, which is useful when working in a small area or near a physical obstruction like a wall. This is configured entirely from the teach pendant.
What you need
- A Doosan robot
- The teach pendant admin password (default:
admin, no capital letters)
Steps
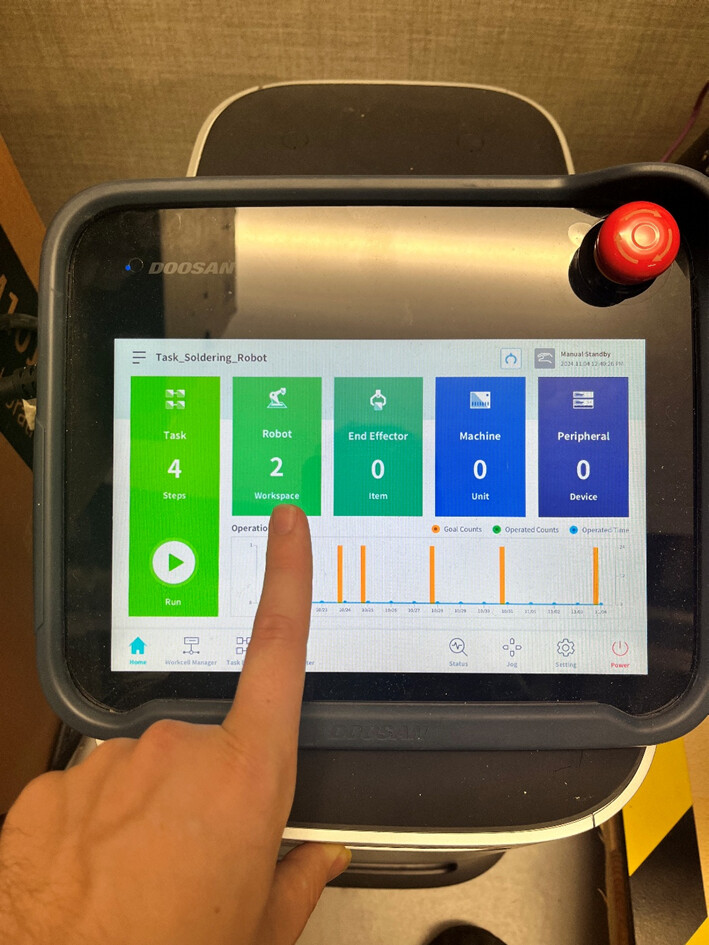
1. Open the Robot menu
On the teach pendant, open the “Robot” menu. From here you can choose different restriction settings: limiting specific joints, or creating a working-space / space restriction.
2. Add a space restriction
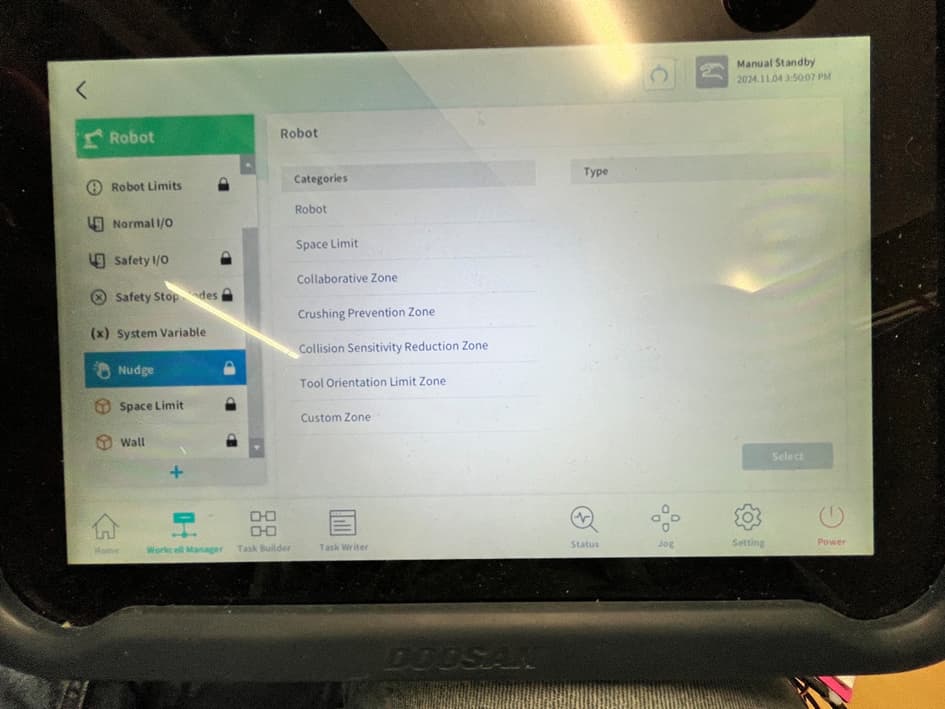
In the robot settings screen, click the plus button at the bottom of the scroll menu on the left.
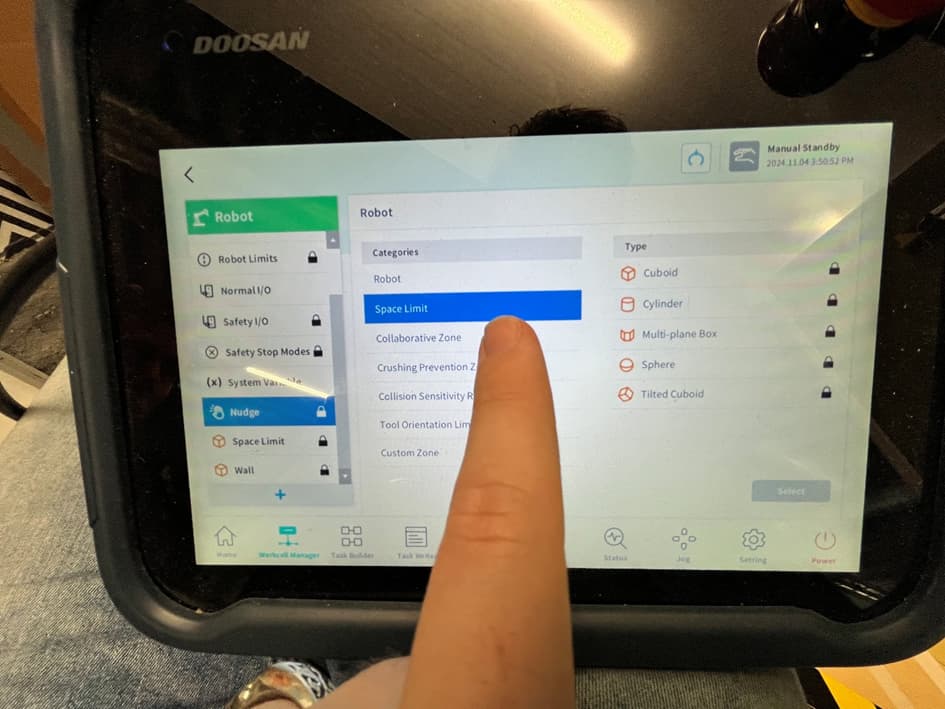
3. Choose “Space Limit”
From the categories list, select “Space Limit”.
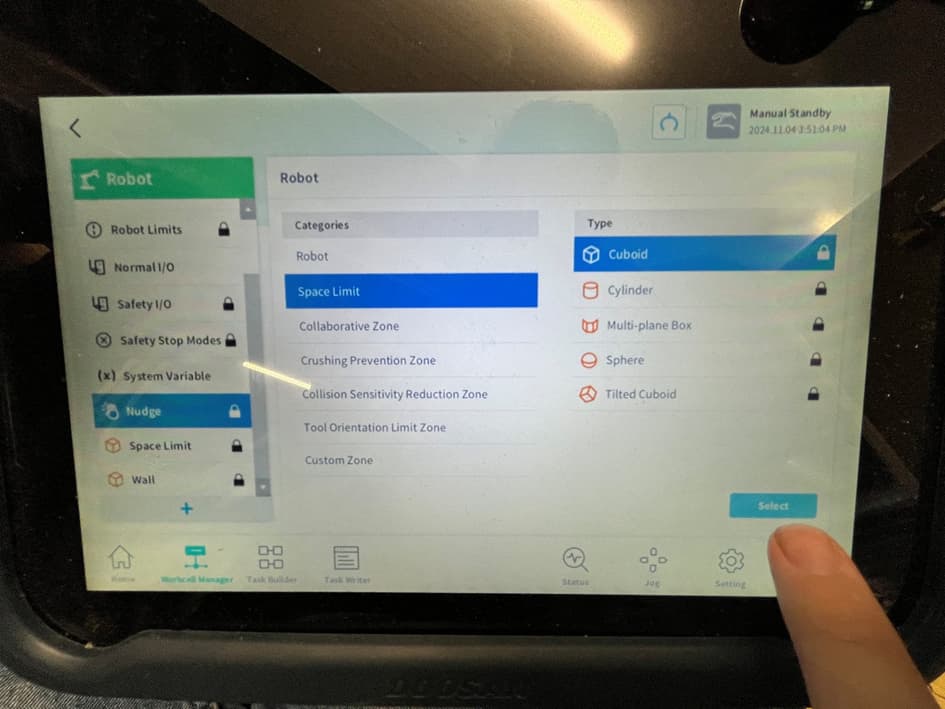
4. Choose a shape
Pick the shape that matches your restricted area (e.g. a cuboid for a square workspace up to a certain height). Press “Select” in the bottom right when done.
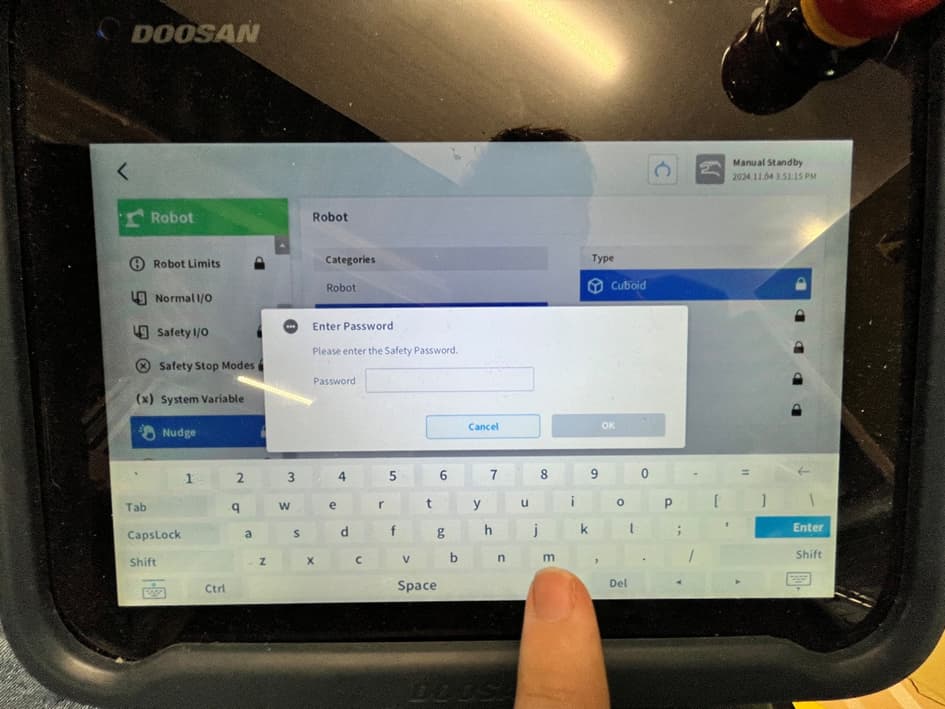
5. Enter the admin password
You’ll be asked for a password to change safety restrictions. The default is admin (lowercase).
6. Choose what the limit applies to
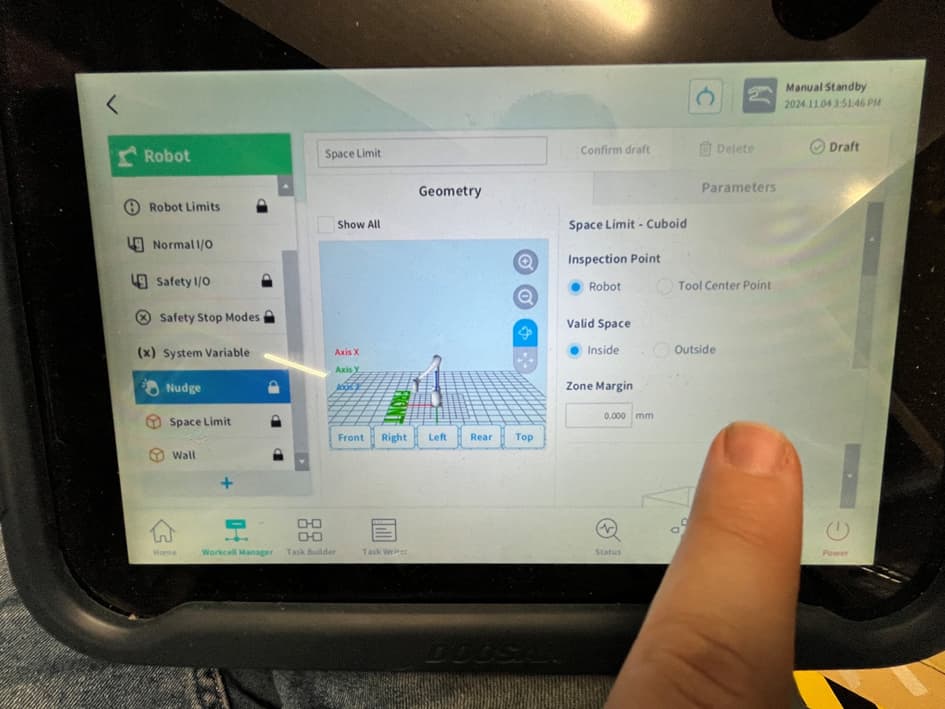
You have two options for what is tracked against the limit:
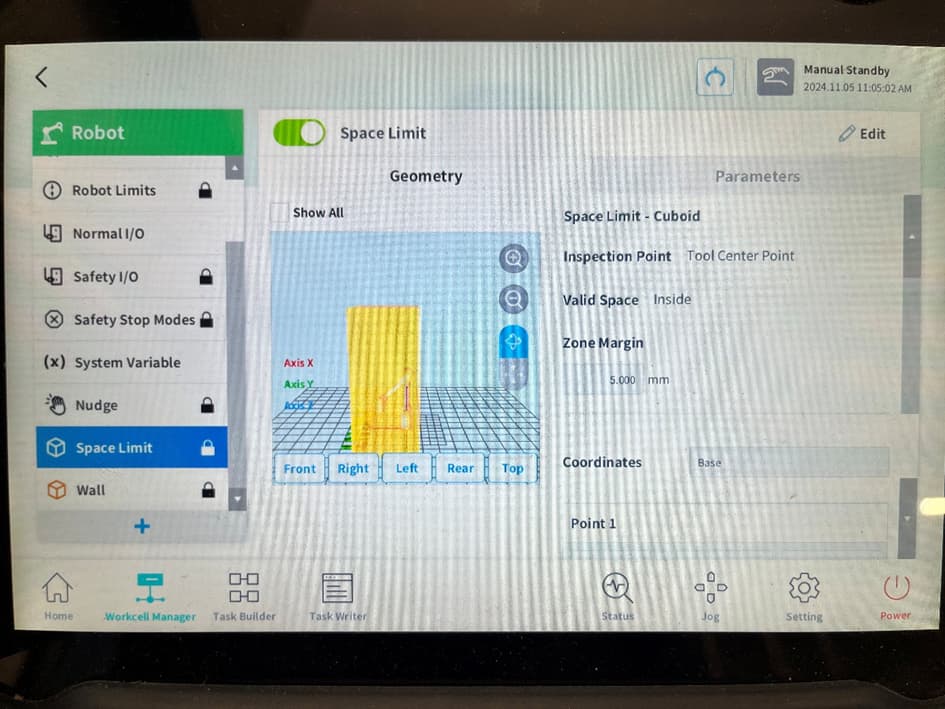
- Tool center point: if you have a tool mounted, you can track its center point and enter its distance from the arm flange.
 The bottom of the space-limit box is always 3 mm above the table the robot is placed on. If you set your tool center point distance exactly, the robot will refuse to move the tool tip down to the table surface. If you need to touch the table, make your tool center point distance 3 mm shorter than the real value.
- The robot itself as an inspection point: the robot’s body is restricted from moving into or touching the walls of the space limit.
When jogging the robot by hand with the tool center point option, the robot pulls itself back into the space limit automatically. You can force it out, but it will then lock itself and show an error on the pendant.
7. Choose the valid space
You also choose whether the robot should always stay inside the space limit, or should never enter it. The second option is useful for simulating a wall or other obstruction behind the robot.
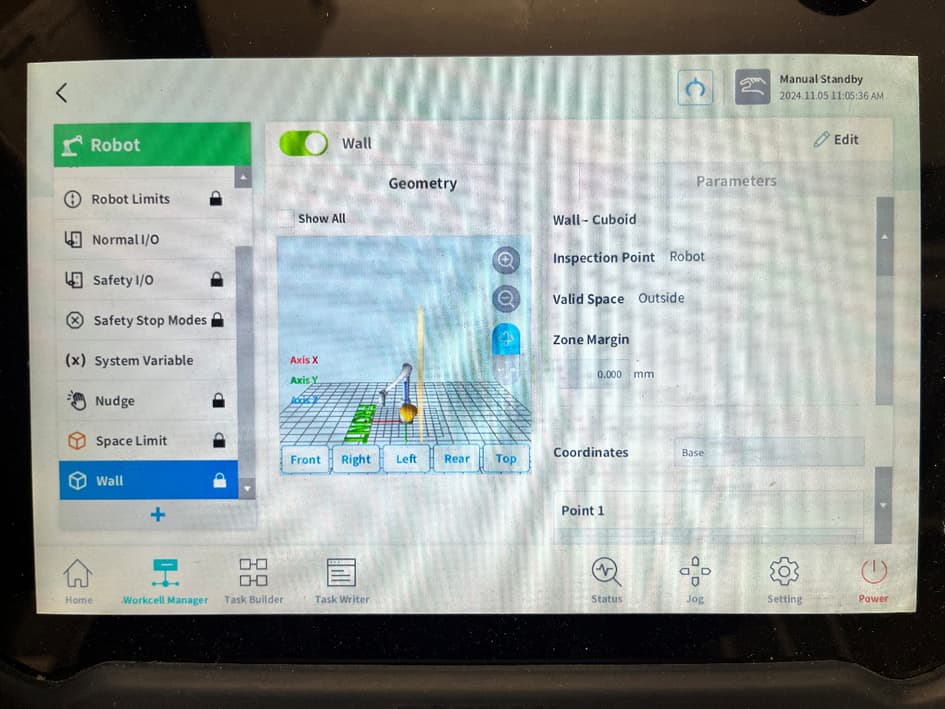
With the robot set as the inspection point and the valid space set to “outside the box”, the robot stops as soon as any part of it touches the space limit, with the same error as above.
8. Set the space limit points
Scroll down to define the corner points of the shape. For a cuboid, you only need two points:
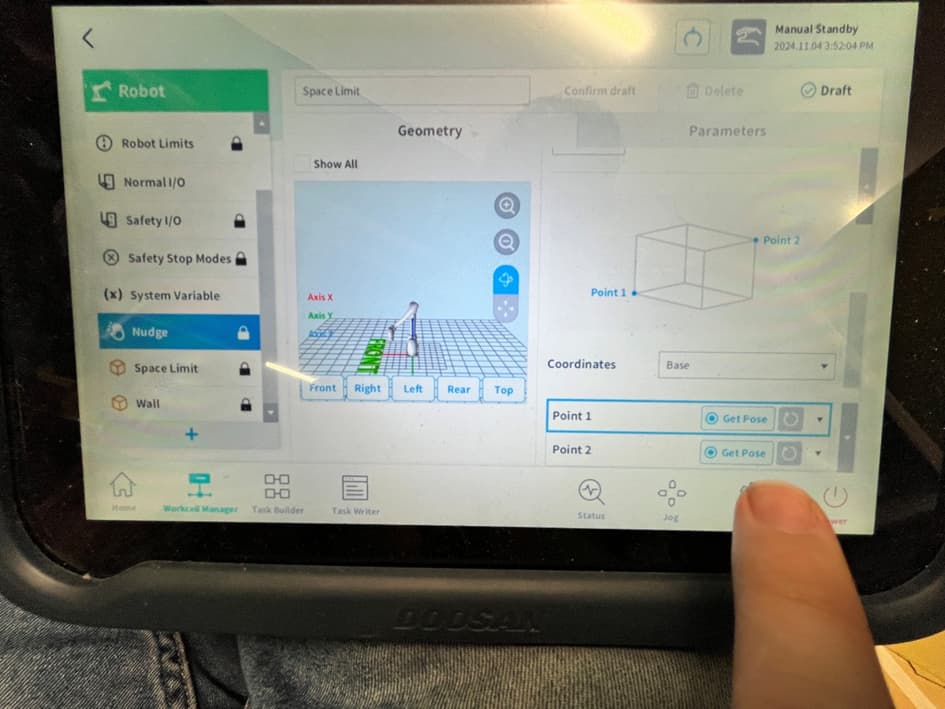
Click point 1, jog the robot (by hand or with the pendant) to the first corner of your space, then press “Get Pose” to capture it. Repeat for point 2.
9. Save
Save your settings by clicking “Draft” in the top right corner.
Recovering from a space limit error
If the robot hits a space limit, the pendant shows an error and the LED ring on the robot head turns red.
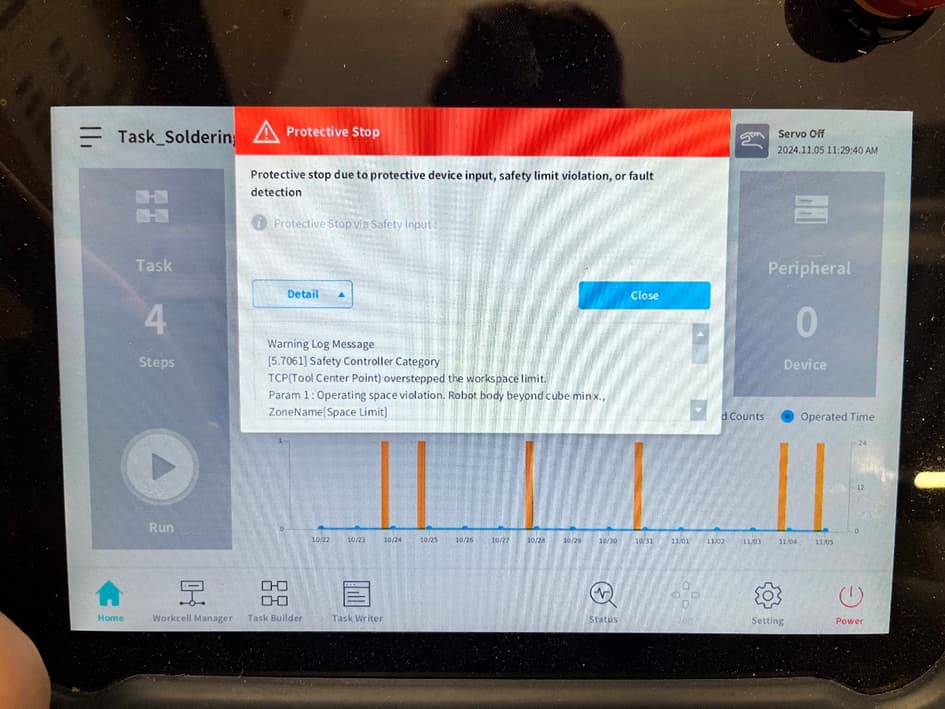
-
Close the error. The robot won’t let you move yet — the screen goes grey.
-
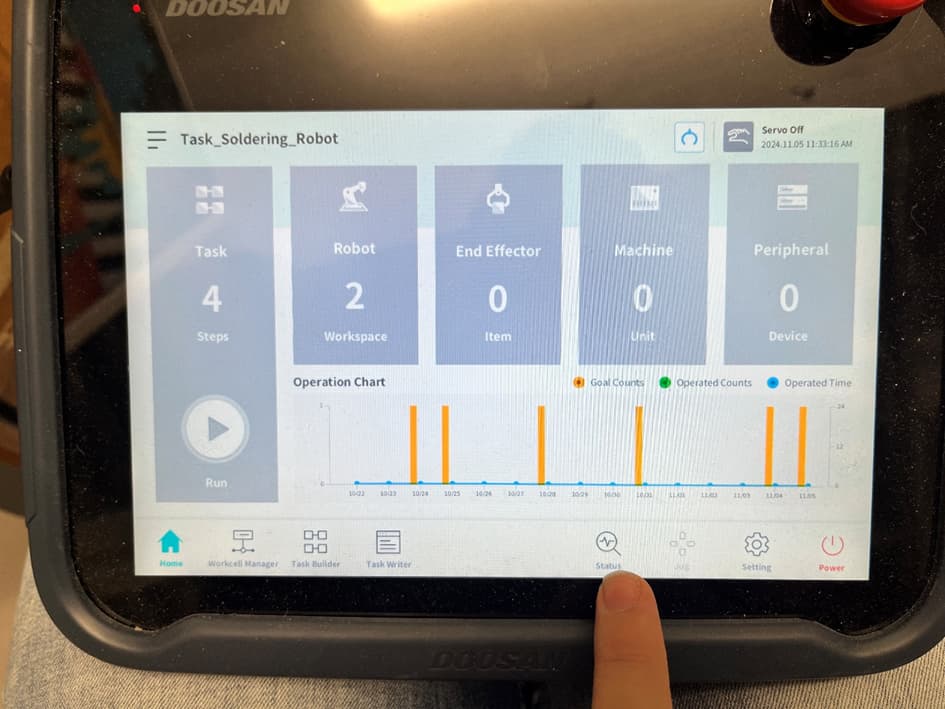
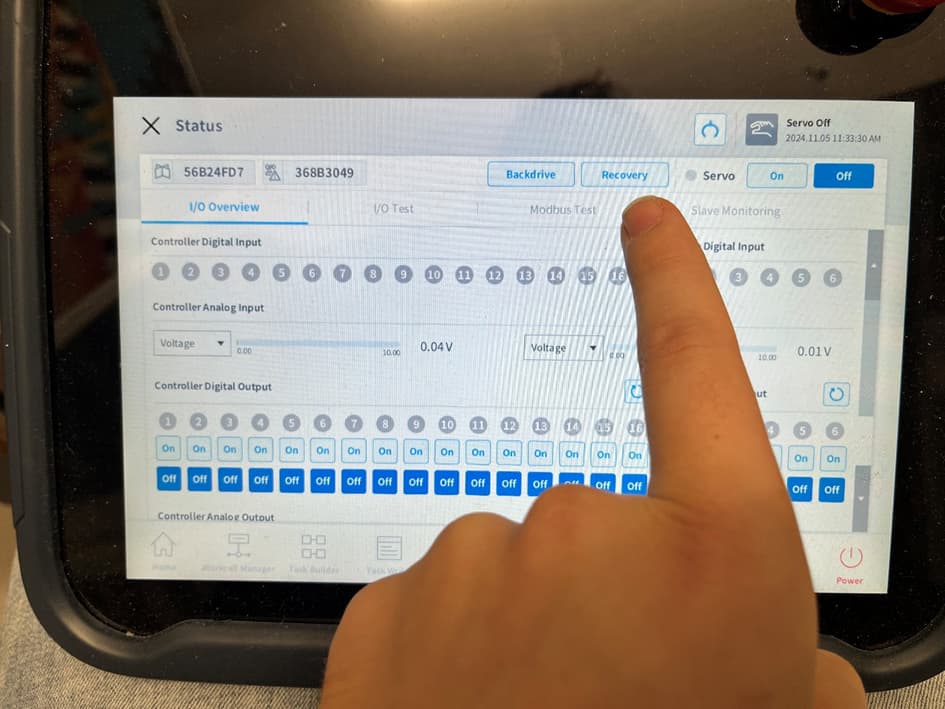
Open the “Status” tab at the bottom of the screen.
-
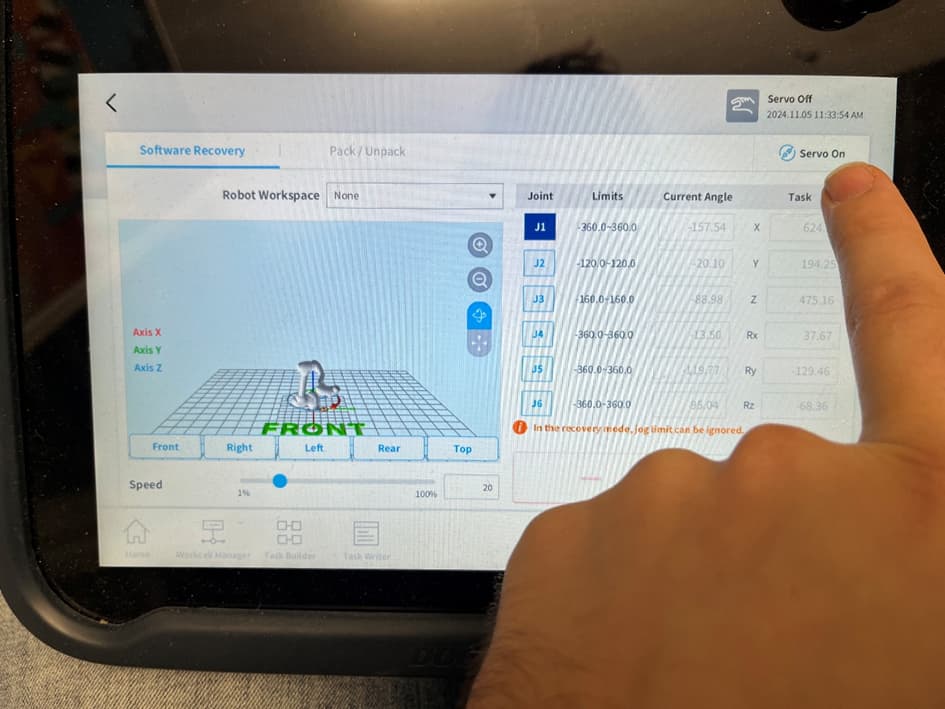
Press “Recovery”.
-
Press “Servo On” in the top right corner before trying to move anything.
-
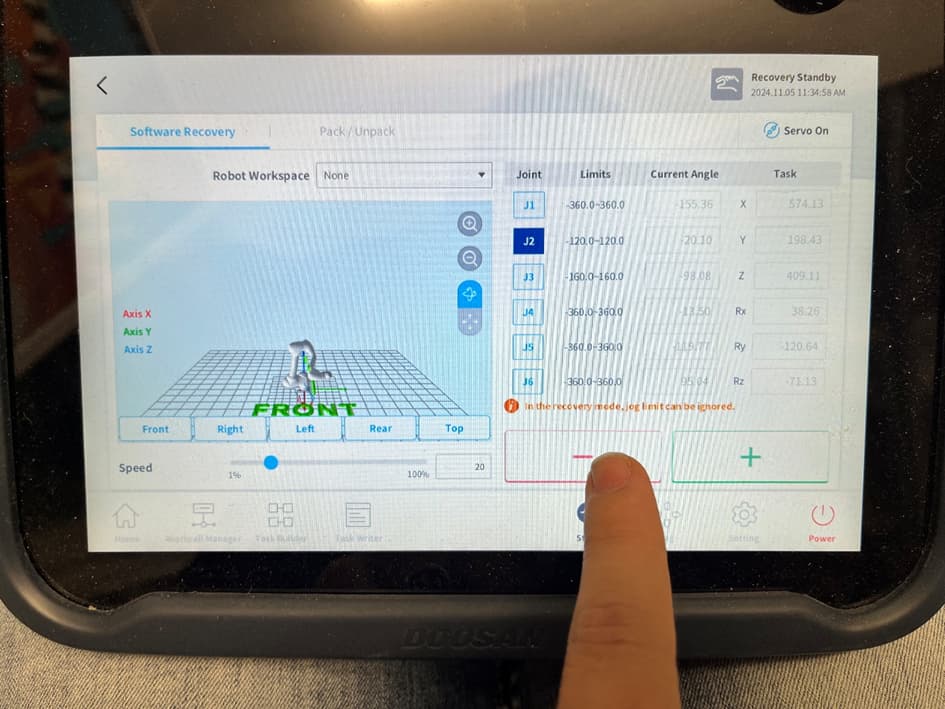
Click individual joints and move them with the
+/-buttons until the robot (or its tool center point) is back inside the space limit. -
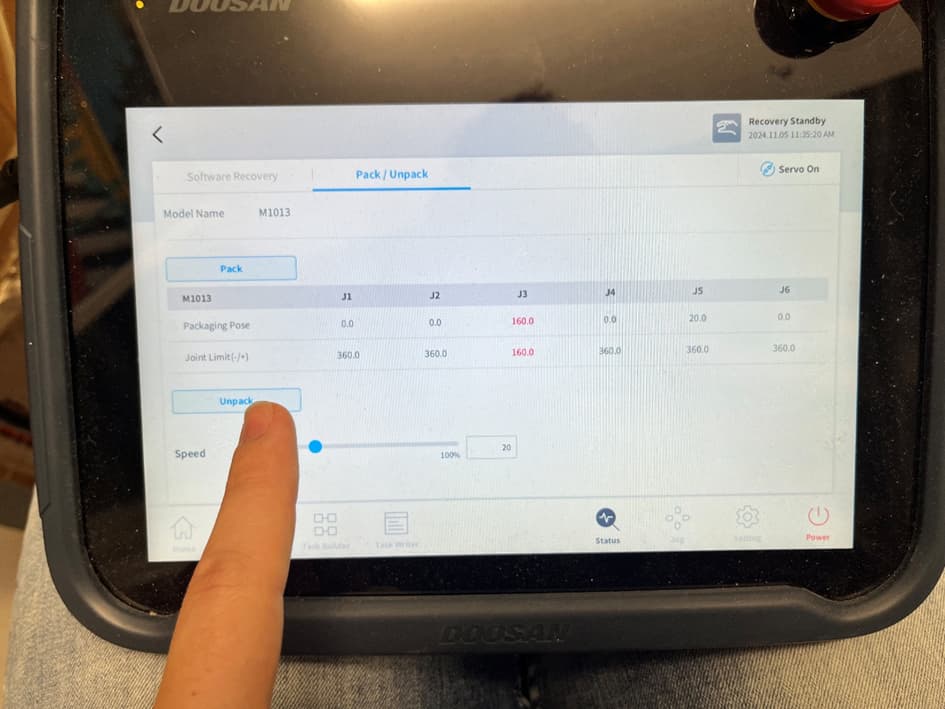
If joint-by-joint recovery doesn’t work or is too fiddly, you can also use the pack/unpack function instead. Note that this moves the robot fully to its upright/pack position (the transport pose) — you don’t need to fully pack or unpack it, just move it until it clears the space limit.
-
Exit recovery mode and return to the home screen. You can jog the robot by hand again once the LED ring on the head is blue.
Troubleshooting
- Forgot the admin password: the default teach pendant admin password is
admin(all lowercase) unless it has been changed for your setup. - Robot won’t move after closing a space-limit error: this is expected — you must go through the Status → Recovery → Servo On flow above before you can jog it again.
Reference
Doosan Robotics Programming Manual (PDF)
Related
- How to mount a Doosan M1013 on a wall or ceiling
- How to move a Doosan robot with movej, movel, and asynchronous motion commands
Rewritten and consolidated (Sept 2026) from the original student how-to’s: How to use safety area limits on a Doosan robot.