Based on contributions by MarijnvdWekken.
A Doosan tool digital input expects a 24V signal, while a microcontroller like an ESP32 or Arduino outputs 3.3V or 5V logic — they cannot be wired together directly. This how-to shows how to level-shift a digital signal between the two using a single NPN transistor, so the robot can wait for or react to a signal from a microcontroller running its own sensor/servo/gripper logic.
What you need
- Doosan robot with a free tool digital input
- Microcontroller (e.g. ESP32 or Arduino)
- 2N2222 NPN transistor
- Pull-up resistor: approx. 10–15 kΩ, from Doosan +24V to the digital input
- Base resistor: approx. 10–39 kΩ, between the microcontroller output and the transistor base
- A multimeter, for testing before connecting to the robot
Steps
1. Understand why a transistor is needed
A Doosan digital input needs 24V to register HIGH. A microcontroller pin only supplies 3.3V or 5V and cannot drive that directly. A transistor is used as an electronic switch instead:
- Microcontroller output LOW → transistor off
- Microcontroller output HIGH → transistor on
- Transistor off → Doosan input is pulled up to 24V
- Transistor on → Doosan input is pulled down to GND
Note that this inverts the signal: microcontroller LOW results in Doosan input HIGH, and vice versa. Account for this inversion in your robot or microcontroller logic.
2. Wire it up
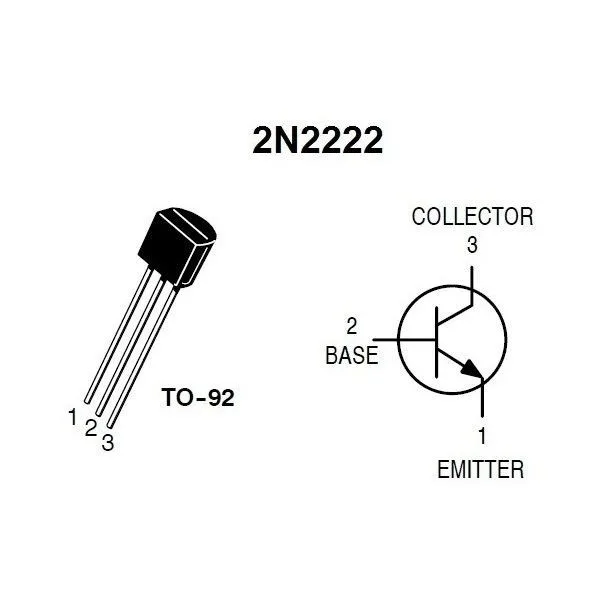
- Transistor collector → Doosan digital input
- Transistor emitter → Doosan GND
- Transistor base → microcontroller output, through the base resistor
- Doosan GND → microcontroller GND (common ground is required)
- Doosan +24V → pull-up resistor → Doosan digital input (this is the same node as the collector)
Do not connect the Doosan digital input directly to +24V without the pull-up resistor in this circuit — the resistor is what limits the current when the transistor pulls the line to GND.
Recommended resistor values:
| Resistor | Value |
|---|---|
| Pull-up, Doosan +24V → digital input | ~10–15 kΩ |
| Base, microcontroller output → transistor base | ~10–39 kΩ |
3. Write the microcontroller test code
This toggles the output every 3 seconds, so you can verify the circuit before wiring it to the robot:
#include <Arduino.h>

const int DOOSAN_SIGNAL_PIN = 15;

void setup()
{
    Serial.begin(115200);

    pinMode(DOOSAN_SIGNAL_PIN, OUTPUT);
    digitalWrite(DOOSAN_SIGNAL_PIN, LOW);
}

void loop()
{
    Serial.println("output LOW -> Doosan DI HIGH");
    digitalWrite(DOOSAN_SIGNAL_PIN, LOW);
    delay(3000);

    Serial.println("output HIGH -> Doosan DI LOW");
    digitalWrite(DOOSAN_SIGNAL_PIN, HIGH);
    delay(3000);
}
4. Test with a multimeter before connecting the robot
Before wiring the collector node to the actual Doosan digital input, measure it directly:
Red probe   -> collector / Doosan DI point
Black probe -> GND
Expected result:
Microcontroller output LOW  -> about 24V
Microcontroller output HIGH -> about 0V
If you see this, it’s safe to connect the point to the Doosan digital input.
5. Read the input on the robot side
In C++ with DRFL, read the tool digital input with get_tool_digital_input:
int input_value = robot.get_tool_digital_input(
    static_cast<GPIO_TOOL_DIGITAL_INDEX>(3)
);

if (input_value == 1)
{
    std::cout << "Doosan input is HIGH" << std::endl;
}
else if (input_value == 0)
{
    std::cout << "Doosan input is LOW" << std::endl;
}
else
{
    std::cout << "Error reading Doosan input" << std::endl;
}
Remember the signal is inverted by the transistor: a HIGH read here means the microcontroller output was actually LOW.
Troubleshooting
 Check: the resistor values above (10–15 kΩ pull-up, 10–39 kΩ base) are the values used in the original setup. They were not verified against the exact input impedance of every Doosan digital input model — always test with a multimeter as in step 4 before trusting the circuit with the robot connected.
- If the multimeter readings in step 4 don’t match, double-check your ground connection first — the Doosan GND and microcontroller GND must be common, or the voltage readings will be meaningless.
Related
- How to use the analog I/O ports on a Doosan robot
- How to connect a weak-signal sensor to a Doosan robot via Arduino and Python
Rewritten and consolidated (Sept 2026) from the original student how-to’s: How to communicate between a Doosan robot and a microcontroller using a transistor.